Results for “Robot”

Journal articles (OpenAlex) Jia Guo · Frontiers in Mechanical Engineering

Fatigue life prediction of variable-load industrial robotic arms based on physics-informed graph neural networks

Introduction Industrial robotic arms operate under long-term variable-load conditions, and joint fatigue accumulation may lead to sudden failures. Conventional life-prediction methods cannot effectively integrate spatial topology, temporal degradation rules and fatigue physical mechanics. This study proposes a physics-informed Graph Attention-GRU (PI-GAT-GRU) model for fatigue-life prediction of variable-load industrial robotic arms. Methods Robotic-arm joints are mapped…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Claudio Gaz, Massimo Cefalo, Alessandro De Luca · Robotica

Dynamic identification and control issues for collaborative robots: the KUKA lightweight robot LWR 4+ case

Abstract Accurate dynamic models are essential for high-performance control, both for trajectory tracking and physical human–robot interaction involving collision detection, reaction, and force control. This work presents a comprehensive framework for dynamic modeling and identification of the KUKA LWR 4+ collaborative robot based on two complementary approaches. The first exploits signals provided by the KUKA Fast Research Interface, combined with nonlinear joint-friction…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Amir Ijaz, Hashem Haghbayan, Juha Plosila et al. · Renewable Energy and Power Quality Journal

Battery-Side Energy Efficiency of Wirelessly Connected Robots Using the Joint Offloading, Compression and Scaling Offloading and Scheduling Policy

Battery capacity is the binding constraint on how long a fleet of mobile robots can work between charges. In wirelessly connected fleets, the robot battery is shared between three competing consumers: locomotion, onboard computation, and the radio. All energy figures in this paper refer exclusively to the robot battery; the edge server is mains-powered and outside the optimisation scope. Offloading perception to the edge server removes computation from the battery, but it…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Liang Wu, Shengyong Xu · Sensors

Terrestrial Bioinspired Robots: Biological Models, Locomotion Modes and a Review of Technological Progress

Terrestrial bioinspired robots emulate the locomotion strategies of land animals and have potential applications in disaster response, planetary exploration, and inspection of complex terrain. This review examines the biological basis of six representative locomotion modes: multi-legged walking and running, elastic jumping, ground-coupled gliding, interface-mediated climbing, peristaltic crawling, and adaptive morphogenesis. It introduces dimensionless descriptors of their…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) David A. Cano-Ibarra, Wendy Flores-Carmona, Karen Roa-Tort et al. · Sensors

Vision-Based Human–Computer Interaction System for Mexican Sign Language Recognition and Robotic Reproduction: Toward Inclusive Educational Applications

Mexican Sign Language (MSL) plays an essential role in communication within the Deaf community, yet access to sign-language learning resources remains limited in some educational settings. This study presents a vision-based Human–Computer Interaction (HCI) system for MSL recognition and robotic reproduction, developed as a proof of concept toward inclusive educational applications. The system uses an RGB camera and MediaPipe Hands for hand-landmark extraction, a multilayer…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Jun You, Xiaer Xiahou, Peng Cui et al. · Buildings

Integrating Construction-Robot Spatial Requirements into BIM-Based Site Layout Checking: A Requirement–Geometry–Rule Workflow Applied to a High-Rise Building Project

Construction robots need space for travel, operation, charging, maintenance, and separation from workers, yet these requirements are rarely planned explicitly on construction sites. Building information modeling (BIM)-based site layout planning formalizes constraints for conventional facilities, and BIM–robot studies address task planning and navigation, but the relations among robot spatial requirements, the volumes reserved for them, and the conditions under which these…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Qilin Liu, Xiaobin Xu, Weiran Li et al. · Robotica

Research on path planning for four-wheel independent drive mobile robots based on minimum turning radius hybrid mode

Abstract Robotic systems are increasingly integrated across various sectors, from manufacturing to logistics, yet robot navigation in construction environments remains challenged by issues such as safety concerns, high energy consumption, and suboptimal operational efficiency. To address these challenges, this study introduces a global path-planning framework for mobile robots based on a four-wheel four-steering (4W4S) kinematic model. The proposed framework combines…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Juyong Hong, Seunghwan Um, Young Gwang Son et al. · Machines

Object-Mesh-Free Dexterous Robot Demonstrations from Human RGB-D Video and Teleoperation

Teleoperating a five-fingered robot hand to collect demonstrations is costly and scales poorly, while human video is abundant yet contains neither robot commands nor robot images. Existing approaches overlay rendered robots on human video, mainly for parallel-jaw grippers; reconstruct object meshes or point clouds in place of the original RGB; or require a wearable exoskeleton during capture. We present a pipeline that composes stationary RGB-D video of a bare human hand…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Sebastian Viancha, Yufeng Huang, Yang Wang et al. · Mechatronics

Cooperative path completion using a modular magnetically levitated planar actuator and a 4-DOF robotic arm

Magnetically levitated planar actuators (MLPAs) offer contactless motion, high precision, and kinematic flexibility, making them promising positioning platforms for industrial manufacturing applications such as laser cutting, visual inspection, additive manufacturing, and painting; however, their integration in cooperative tasks with robot manipulators remains largely unexplored. This study proposes a cooperative framework in which a disc-magnet mover and a 4-DOF robotic arm…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Donato Romano, Gianluca Manduca · npj Robotics

Insect-inspired hexapod robot with magnetically coupled compliant and modular drive system

Legged robots are increasingly inspired by insects’ ability to combine rigidity and compliance for agile, damage-tolerant locomotion in cluttered terrain. Herein, we introduce INSECTRON, a centimeter-scale hexapod robot that employs magnetic transmission to achieve robust mobility with minimal mechanical complexity. Each leg connects to the drivetrain via neodymium magnets, forming a self-aligning micro-clutch that transmits torque under normal load and safely slips under…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Yibo Cao, Jiahong Huang, Zijun Yin · Sensors

Selective Residual Action Chunking for Vision-Guided Multi-Task Robotic Manipulation

Vision-guided robotic manipulation requires control actions that reflect visual observations, robot state, and task goals. Action Chunking with Transformers (ACT) performs well on individual tasks, but shared multi-task policies must accommodate different action distributions and state-dependent control requirements. We propose an ACT-based selective residual action-chunking policy using global and wrist RGB images together with proprioceptive feedback. A task-conditioned…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Xiaobo Wang · Discover Artificial Intelligence

A hybrid IBAS-ISCA route optimization model for mobile robots in static environments

Amidst the fast-paced advancements in mobile robot technologies, route optimization, which forms the crux of autonomous navigation, must strike a balance between obstacle avoidance safety, travel distance, and movement efficiency. This study proposes a dual-layer hybrid route optimization model that combines an improved Beetle Antennae Search and an improved Sine Cosine Algorithm. The model uses Opposition-Based Learning to optimize the initial population. It applies an…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Liu Ruijuan, Bing Zhang, Zhuo‐Yun Nie · Processes

Predictable Performance Control for Trajectory Tracking and Obstacle Avoidance of Differential-Drive Mobile Robots

This paper presents a unified framework for trajectory tracking and static obstacle avoidance of differential-drive mobile robots. A nominal exact-decoupling controller achieves pure exponential longitudinal convergence and globally avoids angular singularities via a stereographic projection; its cascade structure is proved globally asymptotically stable, and a time-scale separation analysis yields an explicit lateral settling-time constant, enabling prescribed convergence…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Pamarthi Venkatasivarambabu, Khyathisree Yarra, Prasanthi Boyapati et al. · Scientific Reports

Reactive path planning for low speed UAVs and mobile robots in static environments using adaptive block coordinate descent logistic regression

Abstract Unmanned aerial vehicles (UAVs) require efficient and reliable path planning mechanisms for safe navigation in obstacle-constrained environments. This study presents an Adaptive Block Coordinate Descent Logistic Regression (ABCD-LoR) model for reactive path planning in static environments using low-cost sensor inputs. The proposed approach formulates obstacle avoidance as a three-class classification problem (no turn, left turn, right turn), where navigation…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Wanru Gong, Xinyi Zheng, Yuan Hui et al. · Robotica

Entropy-controlled intrinsic-motivation reinforcement learning for quadruped robot locomotion in complex terrains

Abstract Learning is the basis of both biological and artificial systems when it comes to mimicking intelligent behaviors. From the classical PPO (proximal policy optimization), there is a series of deep reinforcement learning algorithms which are widely used in training locomotion policies for quadrupedal robots because of their stability and sample efficiency. In this paper, we introduce entropy-controlled intrinsic-motivation (ECIM), an entropy-based reinforcement…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Quanyou Wang, Mingzhang Zhu, Ruochen Hou et al. · Advanced Intelligent Systems

A Hierarchical, Model‐Based System for High‐Performance Humanoid Soccer

The development of athletic humanoid robots has gained increasing attention as advances in actuation, sensing, and control enable increasingly dynamic and practical capabilities. RoboCup, an international competition for fully autonomous robotic systems, provides a challenging benchmark for embodied intelligence, requiring robots to perceive, decide, and act in uncertain and dynamic scenarios. This paper presents the hardware and software innovations underlying an…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Sakthivel Kirubakaran, Surapaneni Renu Deepti, Yetcherla Kumar Sekhar et al. · Pest Management Science

Autonomous Agricultural Robot Framework featuring Temporal Dynamic Graph Neural Network based Semantic Segmentation coupled with Novel Navigation Line Extraction for efficient field operation and intelligent decision making

BACKGROUND: Autonomous agricultural robots support precision farming and improve operational efficiency; however, reliable navigation in complex field environments remains challenging because of inconsistent lighting, variable soil textures, irregular crop growth patterns, and visual occlusions. These conditions hinder accurate crop row detection, semantic segmentation, and navigation line extraction. This study proposes an Autonomous Agricultural Robot Framework Featuring…

Read at Journal articles (OpenAlex)

IEEE Spectrum Robotics David Berreby

Are Drone Ports the Next Annoying Tech Neighbor?

Rick and Marcia LeCompte loved to watch the Cooper’s hawks that frequented a sweet-gum tree in their yard in Baton Rouge, La. But this October, the hawks were gone. Marcia LeCompte is convinced the birds were scared away by the same flying robots that have been vexing the couple since early September. The noise had them spending less time outside in their garden, and even inside their home, they couldn’t escape the near-constant buzzing. Angry and feeling harassed, the…

Read at IEEE Spectrum Robotics

The Register Brandon Vigliarolo SI

Turn your home into a giant crane game with this open source robot

Who needs a humanoid to pick up after you when you can suspend an AI-powered claw from cables near your ceiling?

Read at The Register

Future Farming Geert Hekkert

Earth Rover sells first 10 light-weeding robots

British robotics company Earth Rover has sold its first 10 CLAWS robots, with another 15 under construction. The autonomous machine kills weeds using concentrated pulses of light rather than lasers, herbicides or mechanical tools. The company claims lower energy consumption than laser-based systems.

Read at Future Farming

Robohub IEEE Robotics and Automation Society (RAS)

Robots in society, business and culture: October 2026

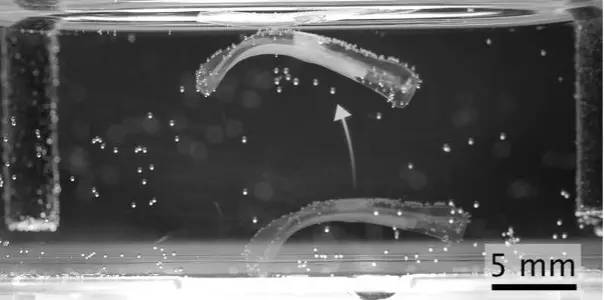
The biohybrid robot pushes off from the ground as soon as it is stimulated by an electrical impulse. Credit: Nature Communications (2026). By Emmet Cole In our monthly series, we showcase a selection of robotics stories from society, business, research and culture, as we track the field’s ongoing journey from specialized industrial machines to an

Read at Robohub

Inc42 Shrishti Bisht Startups

Peppermint Robotics Bags ₹100 Cr To Scale Its Industrial Robotics Bet

Keeping hospital corridors clean or moving goods across factory floors involves repetitive, physically demanding work. For facility management companies, finding…

Read at Inc42

Journal articles (OpenAlex) Juan Daniel Marin-Segura, Luis Antonio Carrillo-Martinez, Debbie Hernández et al. · Machines

Bridging Smart Factory and Industry 5.0: A MAPE-K Autonomic Intralogistics Mobile Robot

Smart Factory paradigms focus on Flexibility, Adaptability, and Digitization, while Industry 5.0 introduces broader systemic priorities focused on Human-Centricity, Sustainability, and Resilience. Although various enabling technologies exist, current literature demonstrates that these six dimensions are typically addressed in a fragmented manner, with limited evidence of their integration within a common experimentally evaluated physical platform. This study investigates…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Qiang Han, Josh Dafoe, Bo Chen · Sensors

Enabling Large Model Inference in Dynamic and Heterogeneous Mobile Robots by Incorporating Collaborative Inference and Model Context Protocol

Modern robotic systems increasingly rely on transformer-based AI models to process sensor input and support high-level decision making. However, due to limited GPU resources in each ego robot, it is difficult to run a large model locally. Outsourcing the model inference to cloud providers could address this issue, which however suffers from limitations including unreliable network connection, high latency, and high monetary cost. In this work, we have developed an effective…

Read at Journal articles (OpenAlex)

Older stories