Results for “Robotics”

Tech.eu Cate Lawrence Startups

Ukrainian drone engineering meets German manufacturing as QFI ramps up production

Quantum Systems and Frontline Robotics are expanding their industrial cooperation through a programme for long-term support capacity in Ukraine aimed at systems developed by Frontline Robotics and pro...

Read at Tech.eu

Semiconductor Digest Shannon Davis

Boston Dynamics & GlobalFoundries Expand Robotics Collaboration

Boston Dynamics, the global leader in mobile robotics, and GlobalFoundries(opens in new tab) (GF), a manufacturer of essential semiconductors, today announced an expansion of their collaboration to deploy Spot for autonomous enterprise asset management across GF’s global semiconductor fabs.

Read at Semiconductor Digest

arXiv (research papers) Onur Beker

A Tutorial on Complementarity-Based Contact Models for Robotics

Simulating rigid-body dynamics with contact is fundamental to robotics, from motion synthesis and control to mechanism design. Many widely used simulators rely on cone complementarity formulations, whose physical assumptions and numerical solution require substantial background. While excellent surveys, monographs, and course notes exist, they mostly address computational mechanics or computer graphics or document a single simulator. To the best of our knowledge, a…

Read at arXiv (research papers)

arXiv (research papers) EngineAI

Awaken-HI: Scaling Humanoid Intelligence with Whole-Body Human Experience

A central goal of humanoid robotics is for robots to perform the everyday work people do in homes and workplaces. Existing egocentric video datasets cover many of these activities but provide little synchronized whole-body motion data for learning loco-manipulation at scale. We build Awaken-Human, which pairs approximately 50,000 hours of egocentric stereo video with synchronized whole-body human motion and covers more than 100 skills. Building on this, we also introduce…

Read at arXiv (research papers)

arXiv (research papers) Mahika Vats

PUPPET: Physical-Unified Platform for Presence, Embodiment, and Teleoperation

Remote access to robotics hardware does not by itself guarantee usable experimental data. A teleoperated trial can complete the task and still produce an incomplete or inconsistent record. PUPPET aims to solve this problem by presenting a cyber-physical framework that opens a physical robotics laboratory through a continuously synchronized VR replica of the robot, stranding environment, and task objects. In addition, PUPPET integrates a trial validation pipeline built into…

Read at arXiv (research papers)

Future Farming Bas Van Hattum

In pictures | Eima focuses on batteries, autonomy and robotics

After Agritechnica, Eima is Europe's second-largest agricultural machinery exhibition. For 5 days, the Italian city of Bologna is packed with machinery and innovations, with a strong focus on batteries, autonomy and robotics.

Read at Future Farming

arXiv (research papers) Guillaume Bellegarda

Learning optimal gaits and styles for terrain-adaptive quadruped locomotion

Animals use many different gaits to locomote at different speeds across varying terrains. A longstanding question in biology and robotics is: which gait is best? This question is most often addressed from an energy-efficiency perspective on flat terrain, leaving open how the answer depends on terrain and on the criterion optimized. Here we show that gait optimality is determined jointly by terrain, performance metric, and velocity. We use deep reinforcement learning and…

Read at arXiv (research papers)

TechCrunch Venture Kirsten Korosec, Theresa Loconsolo Startups

How Toyota is betting on a future beyond cars

Toyota is looking beyond the automotive industry as it places bigger bets on robotics, physical AI, energy, aerospace, and other emerging technologies. Through its venture arm, Woven Capital, the automaker is investing in startups that could help shape what the company looks like decades from now. But as startup valuations climb and competition for promising

Read at TechCrunch Venture

Inc42 Anjali Jain Startups

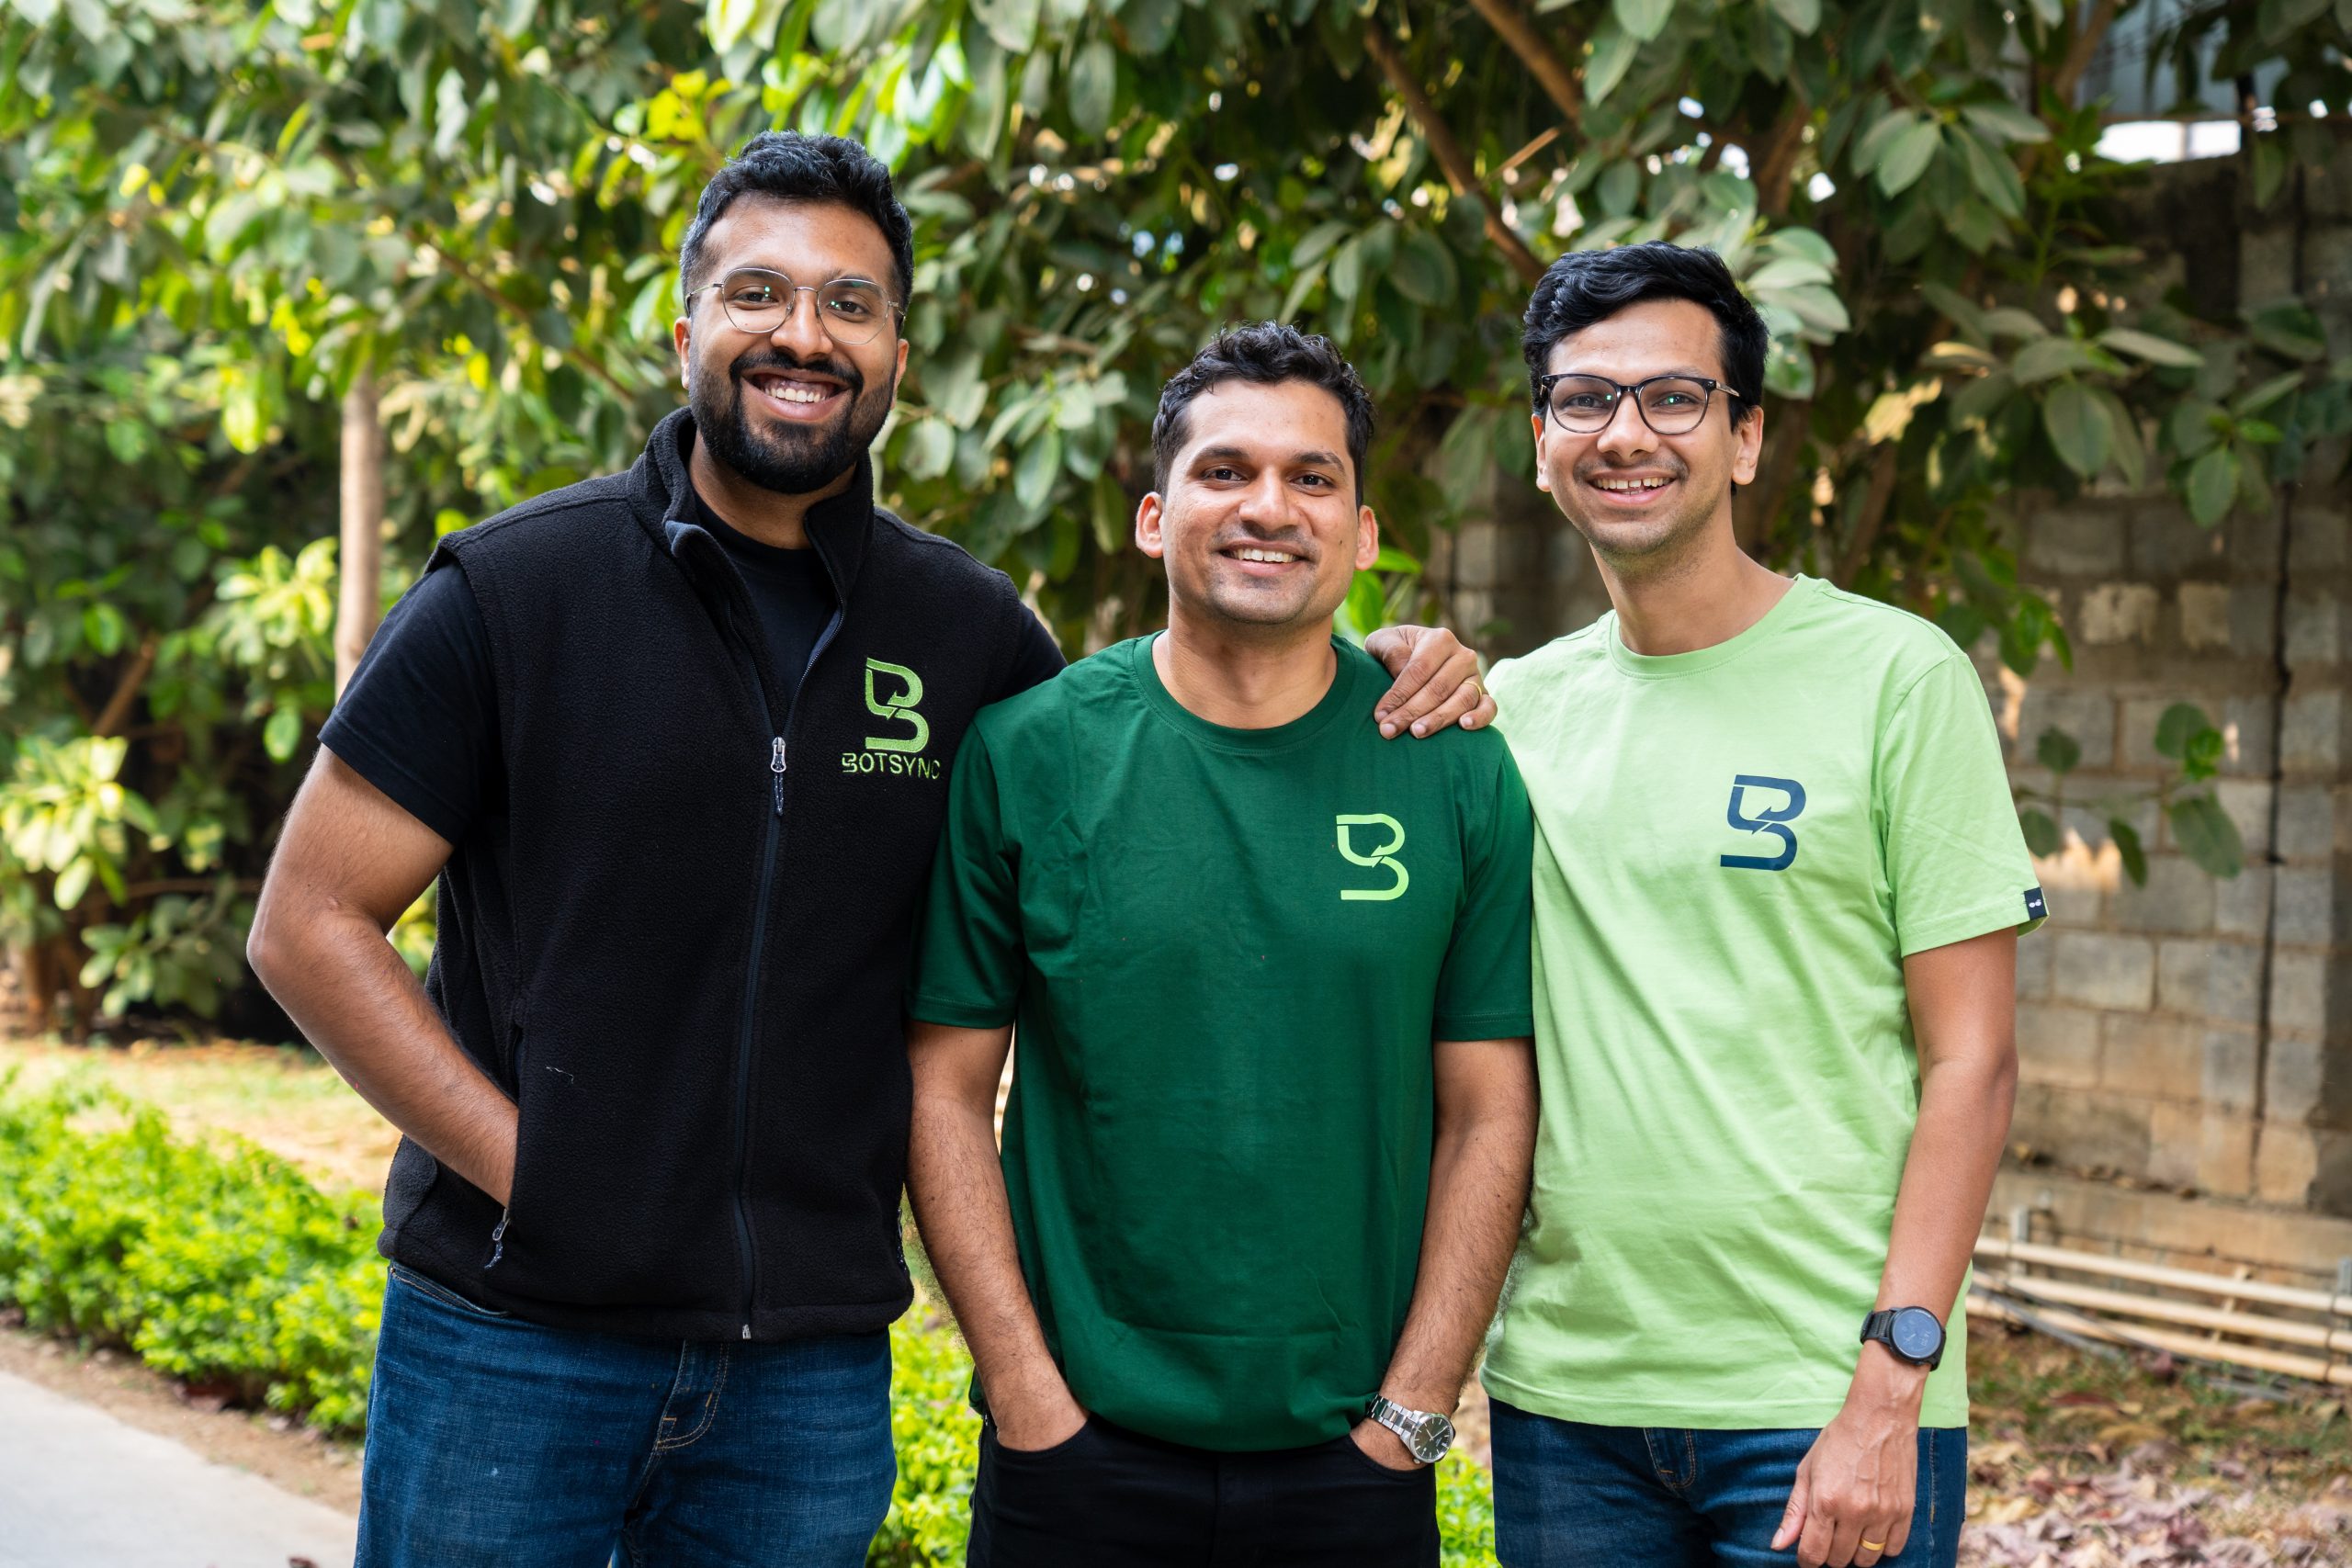
Botsync Raises $11 Mn To Connect Robots And Machines On Factory Floors

Singapore-based robotics startup Botsync has raised $11 Mn (about ₹103 Cr) in a funding round led by IvyCap Ventures to…

Read at Inc42

EE Times Analog Devices

Beyond One Turn: How a Single-Chip Multiturn Position Sensor Is Reshaping Actuator Design

Discover how advanced multiturn position sensing can transform industrial motion control without the limitations of traditional mechanical solutions. Explore how magnetic sensing technology enables accurate, reliable tracking of rotational movement even when power is removed. From robotics and linear actuators to hoists, winches and automated systems, learn how this innovative approach can simplify designs, improve

Read at EE Times

SiliconANGLE AI Kyt Dotson SI

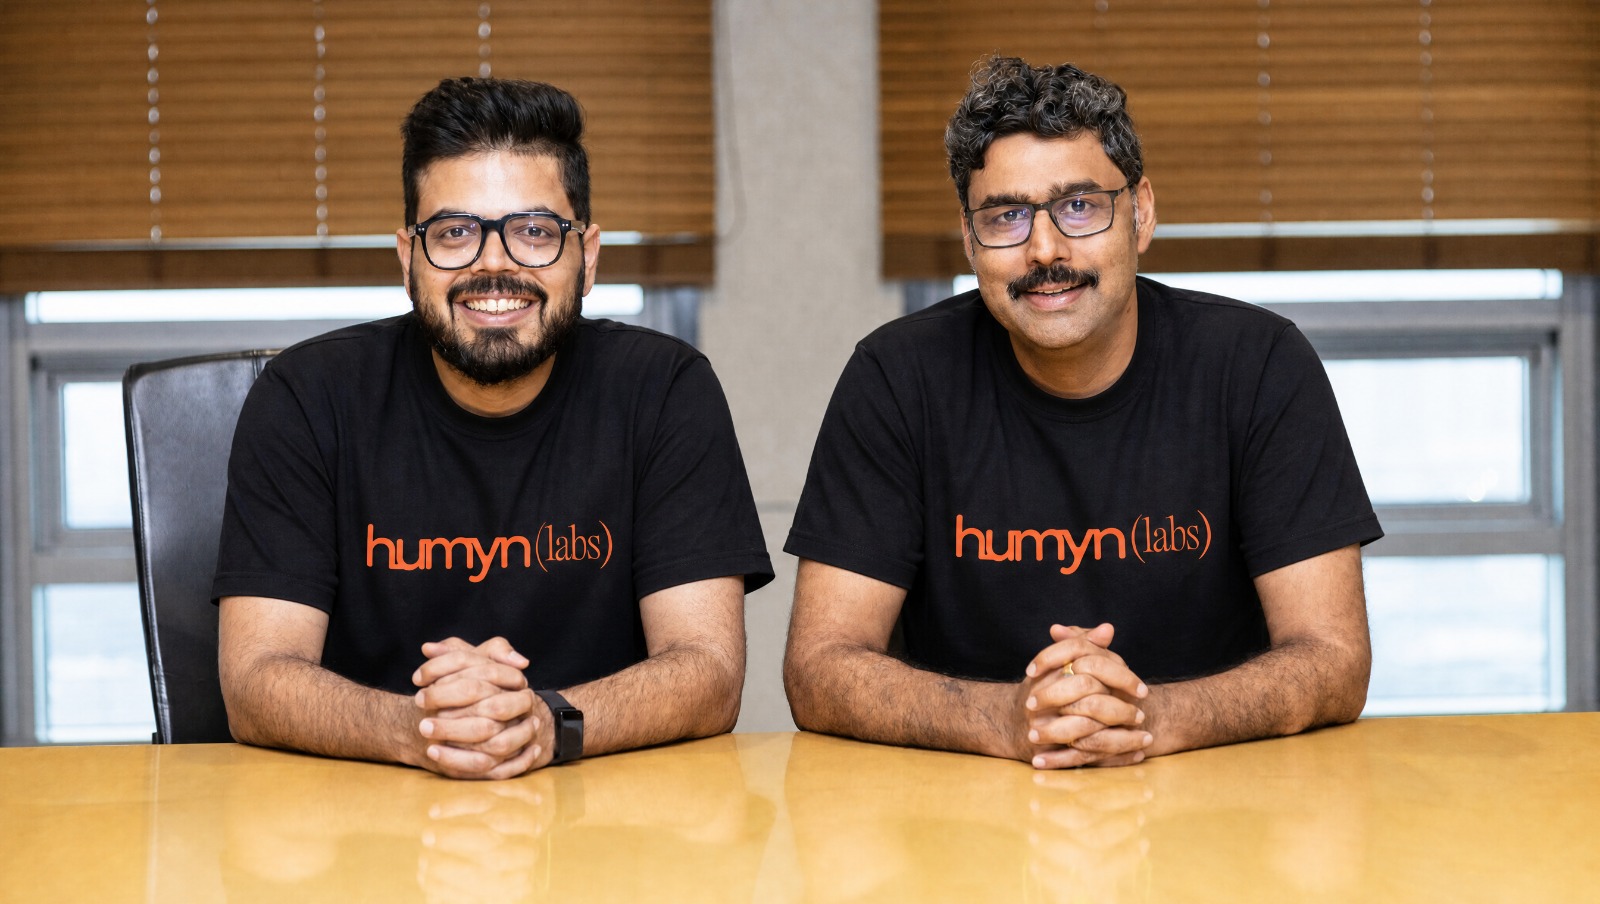
Humyn Labs raises $47M to bridge the gap between AI training and real-world robotics

Humyn Labs, a company turning human experience into training for robots and artificial intelligence, today announced it has raised $47 million in early-stage funding to accelerate intelligent robotic deployment readiness in real-world environments across Brazil, South Korea and India. Accel led the $26 million equity portion of the round, with participation from Prosus Ventures, BeeGlobal,

Read at SiliconANGLE AI

Tech in Asia Grace Priscilla Teo Startups

Indian physical AI startup Humyn Labs raises $47m series A

The robotics training-data provider says it runs operations in more than 20 countries.

Read at Tech in Asia

TechCrunch AI Jagmeet Singh SI

India’s Humyn Labs raises $47M to feed U.S. robotics companies the data they need

Founded in February, Humyn Labs competes with startups including Mecka AI and XDOF, with about 90% of its revenue coming from the U.S.

Read at TechCrunch AI

YourStory Startups

Botsync raises $11M to expand industrial automation

Botsync has raised $11 million led by IvyCap Ventures to advance its AI-powered industrial automation platform, improve robotics capabilities and expand its presence in India and global markets.

Read at YourStory

Tech in Asia Diya Lal Startups

SG robotics startup Botsync secures $11m led by IvyCap

Capital 2B, AppWorks, Iterative, AngelCentral, Genesis Alternate Investments, and angel investor Nalin Advani also joined the round.

Read at Tech in Asia

Tech in Asia Minh Le Startups

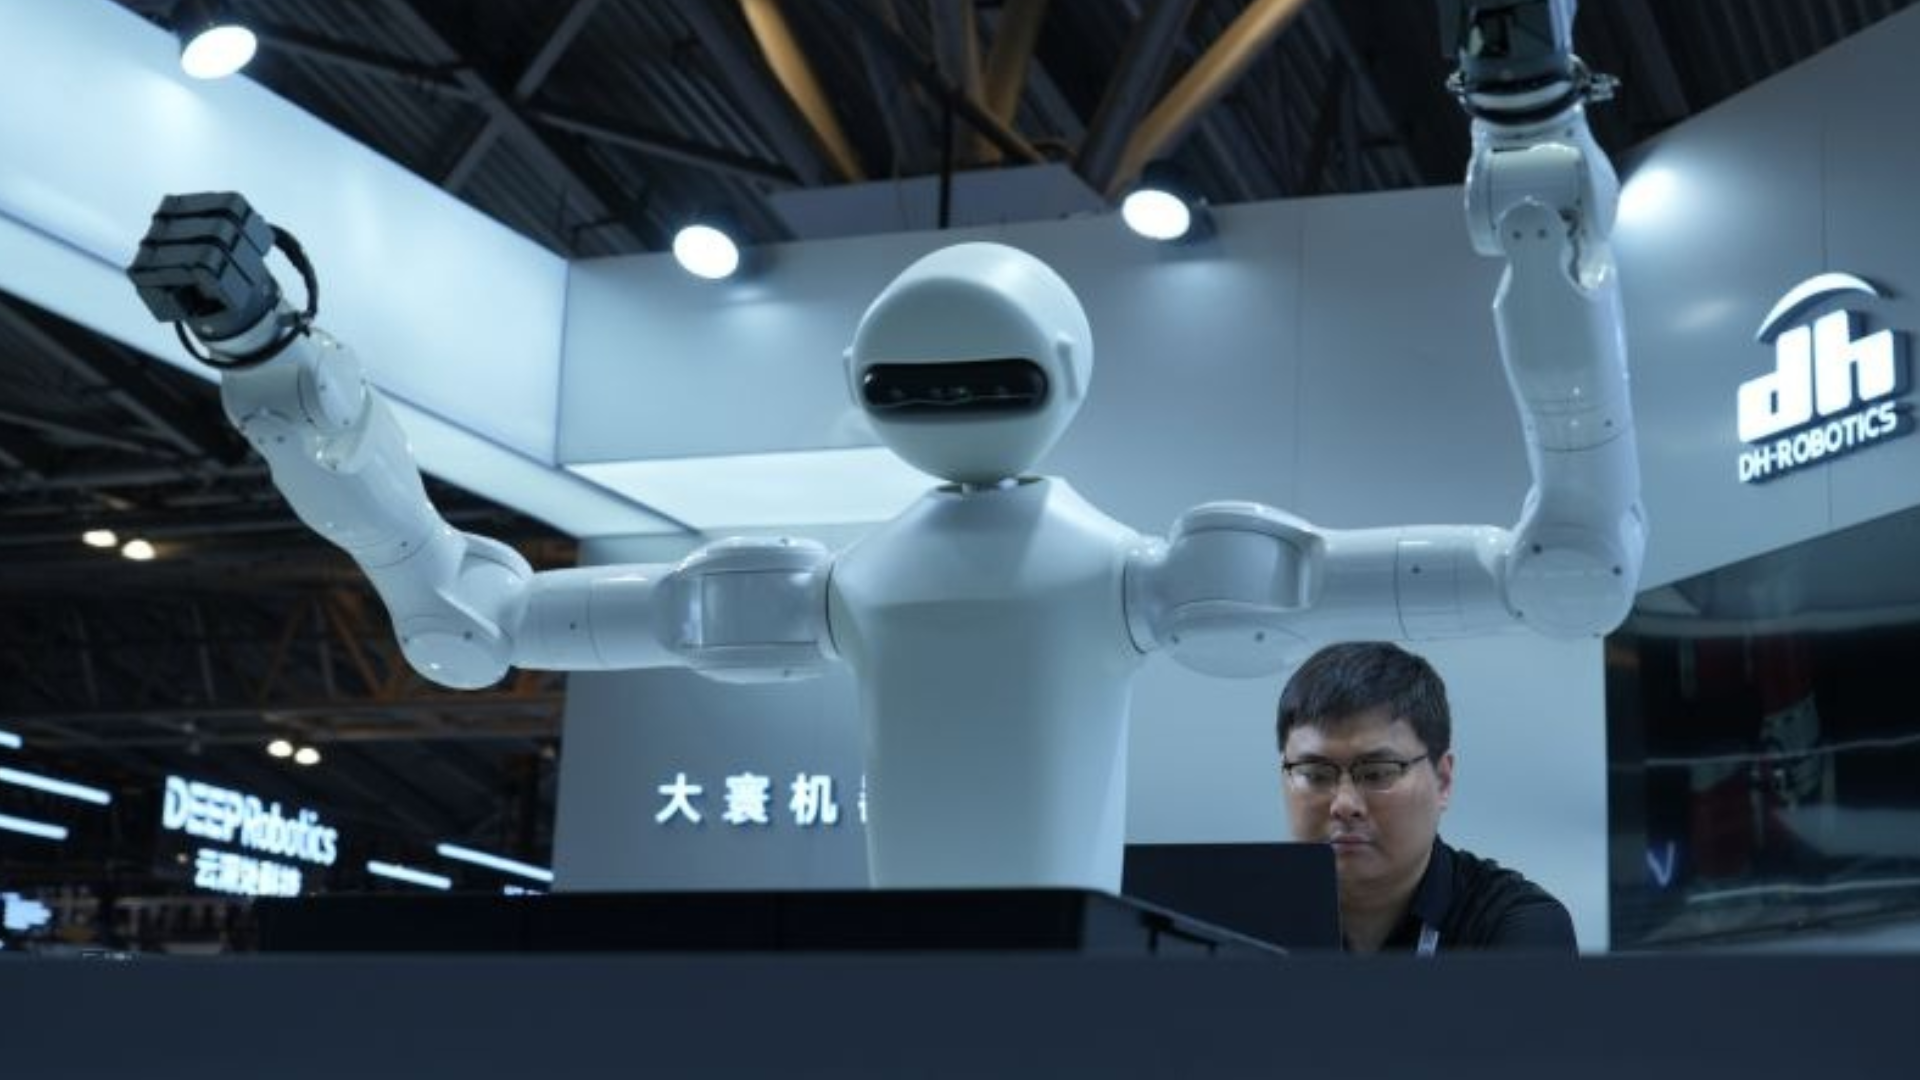
Chinese robotics maker DH-Robotics takes step toward IPO

Founded in 2016, DH-Robotics' products are used in supply chains of BYD, CATL, and Huawei.

Read at Tech in Asia

arXiv (research papers) Thomas A. Berrueta

Recoverability, Not Invariance: Certified Safety for Robots at the Limits of Performance

Safety certification in robotics typically rests on forward invariance of the deployed controller, a property that demands high-fidelity models at the edge of the operating envelope, exactly where models are least reliable and robots perform best. As a result, many of the behaviors we most want robots to run, from learned policies to aggressive maneuvers at the limits of traction, cannot be certified at all. We introduce recoverability, a contraction-theoretic safety concept…

Read at arXiv (research papers)

South China Morning Post Iris Deng,Vincent Chow Geopolitics

Shenzhen – once a fishing village, now China’s ‘Robot Valley’ – takes the Apec stage

Standing on a 53rd-floor balcony overlooking the Yangtai and Tanglang Mountains in Shenzhen’s Nanshan district, Liu Tuo finally managed to catch his breath. He had spent the entire day leading back-to-back foreign delegations on tours around his robotics showroom, which features calligraphy-writing humanoids, kickboxing bipedal bots and motorised exoskeletons. Recent visitors to his showroom in Shenzhen’s so-called Robot Valley included old-money European hoteliers browsing…

Read at South China Morning Post

arXiv (research papers) William Dubois

Pressure Drop: Gravity Vector Estimation from a Distributed Barometric Pressure Sensor Array

While gravity is often used in mobile robotics as a global constraint for Simultaneous Localization and Mapping (SLAM) algorithms, most estimation methods rely on indirect observation of the gravity vector. In this paper, we propose the use of altimeter measurements to directly observe the direction of the gravity vector. We provide a theoretical evaluation of the estimation noise and validate it through extensive experimental data, along with an evaluation of the impact of…

Read at arXiv (research papers)

The Quantum Insider Matt Swayne

SAXON Q Announces ‘Quantum Watchdog,’ to Detect When Quantum Computers Fail

Insider Brief PRESS RELEASE — SAXON Q, a leader in NV-center quantum computing, today announced the Quantum Watchdog, a patented safety system that monitors a quantum computer and puts it into a safe mode if it fails. The system is designed for quantum computers operating in research environments and upcoming industrial applications — including robotics,

Read at The Quantum Insider

arXiv (research papers) Aria Dadnavi

Technical Report of Mobile Manipulator Robot for Industrial Environments

This paper presents the design and implementation of Auriga Robotics' mobile manipulator robot, developed at the Robotics and Intelligent Automation Laboratory, Department of Electrical Engineering, Shahid Beheshti University. Hereafter, this platform is referred to as the @Work Robot. The robot targets industrial tasks, with an emphasis on improving efficiency in repetitive or hazardous work environments. It uses a 4-wheel Mecanum drive for omnidirectional movement and a…

Read at arXiv (research papers)

arXiv (research papers) Stanley Akingbola SI

Network-Exposed Configuration Attacks on LLM-Controlled Social Robots

Large language models (LLMs) in embodied robots create security dependencies beyond inference. We investigate a network-exposed configuration attack on the Pollen Robotics Reachy Mini Lite, allowing an unauthenticated attacker to replace personality settings and the cloud LLM's system prompt through a management interface, without adversarial conversational input. Eleven prompt-injection attempts across five categories were reported as resisted, whereas both…

Read at arXiv (research papers)

arXiv (research papers) Lorenzo Paiola

Risk Density RRT$^*$: Planning in the Space of Probability

Planning under uncertainty is a fundamental problem in robotics. While much of the literature seeks minimum-cost paths subject to probabilistic constraints, this paper instead considers collision probability, or risk classically defined as probability times severity, directly as the planning objective. We propose Risk Density RRT$^*$ (RD-RRT$^*$), an extension of RRT$^*$ for high-level planning in environments with deterministic and uncertain obstacles. RD-RRT$^*$ builds on…

Read at arXiv (research papers)

arXiv (research papers) Mingcheng Zhu

VLM-guided Grounding Expert for Generalised Referring Expression Comprehension

Generalised referring expression comprehension (GREC) aims to identify and localise the zero, one or multiple objects referred to by a language expression. In robotic manipulation, grounding also needs to remain accurate when requests for the same objects are paraphrased or embedded in additional context in robotics. However, grounding expert models are sensitive to instruction variation, while generative vision--language models (VLMs) struggle with complete target recovery…

Read at arXiv (research papers)

arXiv (research papers) Lorenzo Paiola

Task Convergent Flow Matching for Generative Robotics

Successful manipulation requires the manipulated objects to progress toward a desired task outcome. Generative policies can produce plausible robot motions without ensuring this progress, allowing successive action chunks to stall or undo earlier changes to the scene. We introduce a task-centric inference-time refinement framework for flow matching policies that evaluates candidate action chunks through parallel physics-based rollouts and searches for motions satisfying…

Read at arXiv (research papers)

YourStory Startups

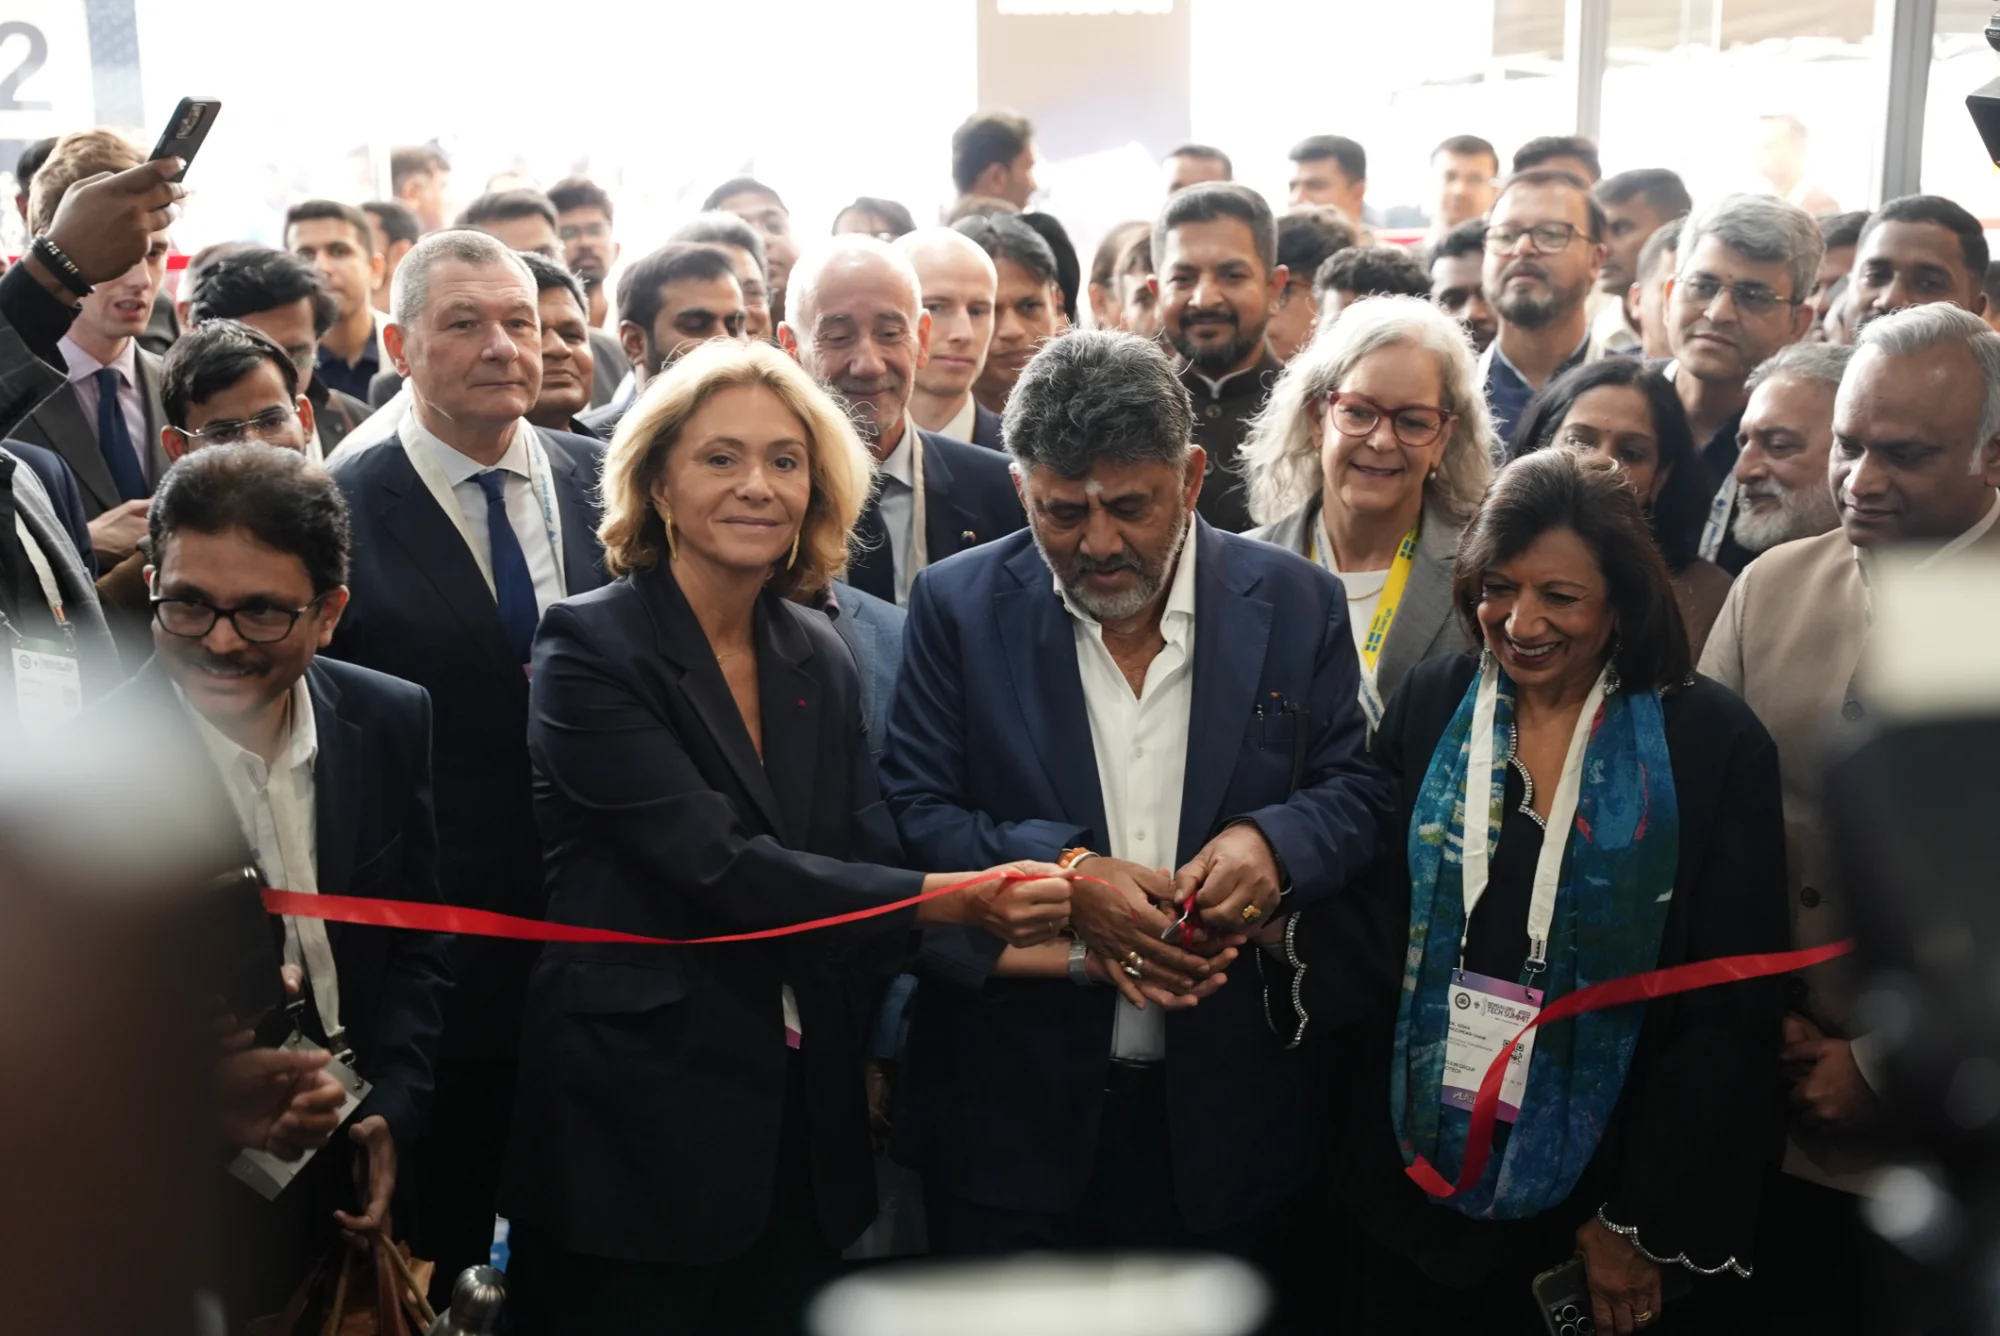
Karnataka aims to become global hub for frontier technologies: DK Shivakumar

Karnataka Chief Minister DK Shivakumar said the strong technology ecosystem in the State gives it the advantage to lead in areas such as AI, biotech, semiconductor and robotics.

Read at YourStory

Analytics India Magazine Ridhika Basnet SI

Karnataka Unveils 6 Initiatives to Strengthen AI and Semiconductor Ecosystem

The state government highlighted six initiatives across AI, robotics, semiconductor research, and healthcare at the Bengaluru Tech Summit 2026.

Read at Analytics India Magazine

YourStory Startups

How friends from Coimbatore built GOAT Robotics into an Rs 8 crore business with global reach

Coimbatore's GOAT Robotics grew from a 2BHK startup to an Rs 8 crore business, serving Toyota, Volvo and global clients.

Read at YourStory

Financial Times China

China’s robot makers have more to offer than viral backflip videos

Established robotics companies are continuing to grow and many are highly profitable

Read at Financial Times China

Older stories