Results for “Robot”

Journal articles (OpenAlex) T. Watanabe, Yoshiki Wakai, Yuuzi Tamai et al. · Eng—Advances in Engineering

Optimal Design of Ground-Penetrating Robotic Arms Using RFT-Based Ground Resistance Analysis

In recent years, robotic systems, including robotic arms, have been increasingly investigated for lunar and planetary exploration. Robotic arms are particularly important for tasks such as sample collection and subsurface exploration. Since the surfaces of the Moon and Mars are covered with soft granular materials, the design of robotic-arm link lengths that reduce energy consumption while considering ground reaction forces and required motions is important for ground…
Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Weifeng Zhang, Yangfei Zhao, Renbo Liu et al. · Journal of Eye Movement Research

Recognition of Intentional Eye-Movement Behaviors for Assistive Human–Robot Interaction

For individuals with limited limb function, conventional manual control methods such as joysticks are not readily applicable to assistive robot operation, highlighting the need for a hands-free control method. Eye movements, as natural signals of human intention, offer advantages in intuitiveness and accessibility and are particularly suitable for such scenarios. However, prior studies have primarily focused on fixation-based gaze interaction, and relying solely on fixation…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Enrique Coronado · Education Sciences

Innovator 5.0: Integrating Design Thinking and Responsible Innovation into AI and Robotics Research Environments for Industry 5.0 and Society 5.0

Industry 5.0 and Society 5.0 call for a shift in AI and robotics development from a primary focus on automation and technical sophistication to holistic solutions that address human needs, social contexts, stakeholder perspectives, and broader societal impacts. Preparing future engineers for this shift requires educational approaches that connect technical development with design thinking and responsible innovation. To address this need, this study introduces Innovator 5.0…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Yifan Yang, Yahao Bai, Lilu Liu et al. · Journal of Zhejiang University. Science A

Visual servoing control of a robotic colonoscope for gastrointestinal examination

Robotic colonoscopy may reduce patient discomfort and operator dependence, but reliable steering remains challenging because intraluminal images contain specular reflections, ambiguous lumen boundaries, occlusion, and anatomy-dependent appearance changes. This paper presents an interpretable low-level vision-guided steering framework that links lumen perception, an explicit image-plane geometric target, and error-dependent gain-scheduled visual servoing. A recurrent residual…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Yanchen Ye, Can Xu, Sen Wang et al. · Science Advances

Adaptive dual-programming magnetic soft robot with lifelike behavior

Magnetic soft robots with embodied intelligence of multimodal motions, environmental perception, and functional decoupling depend on ingenious material arrangement and programmable morphing information introduction. While some efforts have been made, achieving lifelike behaviors for soft robots in system-level strategy remains a notable challenge. Here, we present dual-programming hydrogel-based soft robots (DHSRs) that couple magnetic and anisotropic programming through the…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Zihan Chen, Xi He, Jing Zhao et al. · International Journal of Humanoid Robotics

Multi-Strategy Enhanced Grey Wolf Optimizer with Non-Uniform Mutation for Industrial Robot Path Planning in Complex Manufacturing Environments

To address the core drawbacks of traditional robot path planning algorithms in complex constrained environments, including local optima trapping, imbalance between global exploration and local exploitation, and difficulty in coordinating path feasibility with overall performance, this paper proposed a path planning method based on multi-strategy fused Non-Uniform Mutation Improved Grey Wolf Optimization (NUMIGWO). The algorithm integrated four core strategies: piecewise…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Chuang Zhi Wu, Chongjing Cao · Actuators

Constraint Mechanism Design for Fast Dielectric Elastomer Actuator-Driven Capsule Robots

Dielectric elastomer actuator (DEA)-driven capsule robots convert periodic excitations into net translation through passive constraints, yet a systematic study on optimal constraint design remains largely unexplored. To address this gap, we present a comparative numerical study of six passive constraint families that range from linear and bistable springs to limit stops and polynomial shapes and encompass 2447 configurations under a reference condition. The best…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Shaoyan Zhang, Semyon Bodian, Nyma Nassren et al. · Frontiers in Medical Technology

Robotic bronchoscopy delivery of optical ultrasound imaging for transbronchial lung biopsy guidance

Accurate guidance for transbronchial pulmonary nodule biopsy requires visualisation of targets and tools beyond the airway wall, yet radial endobronchial ultrasound provides only a cross-sectional image orthogonal to the probe axis, and must be withdrawn before a tool is passed, leaving tissue acquisition unguided. Optical ultrasound (OpUS) imaging offers a miniaturised, fibre-based alternative that may enable image guidance from within the narrow distal bronchi. In this…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Byron Ricardo Zapata, Jaime Heredia, Víctor Ruiz-Díez et al. · Actuators

Experimental Assessment of Control Strategies and Environmental Perception in an Autonomous Piezoelectric Miniature Robot

This work presents the functional enhancement of a previously developed miniature robot actuated by 3D-printed piezoelectric resonators through the integration of environmental and spatial sensors and the experimental comparison of proportional-derivative (PD) and sliding mode control (SMC) strategies. The platform integrates an inertial measurement unit, a time-of-flight distance sensor, and a total volatile organic compound (TVOC) sensor, enabling the robot to execute a…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Kapalik Khanal, Biswash Khatiwada, Stephen Afrifa et al. · AgriEngineering

Vision–Language–Action Model for Agricultural Fresh Produce Handling with a Humanoid Robot

Reaching, grasping, and placing fresh produce is among the most labor-intensive operations in agricultural production, yet most robotic solutions remain task-specific, single-crop systems that generalize poorly across the morphological diversity of fresh produce. This study investigates whether a large, pre-trained Vision-Language-Action (VLA) model can be adapted, with only modest demonstration data, to serve as a flexible language-conditioned produce-handling policy on a…

Read at Journal articles (OpenAlex)

TechCrunch Kirsten Korosec SI

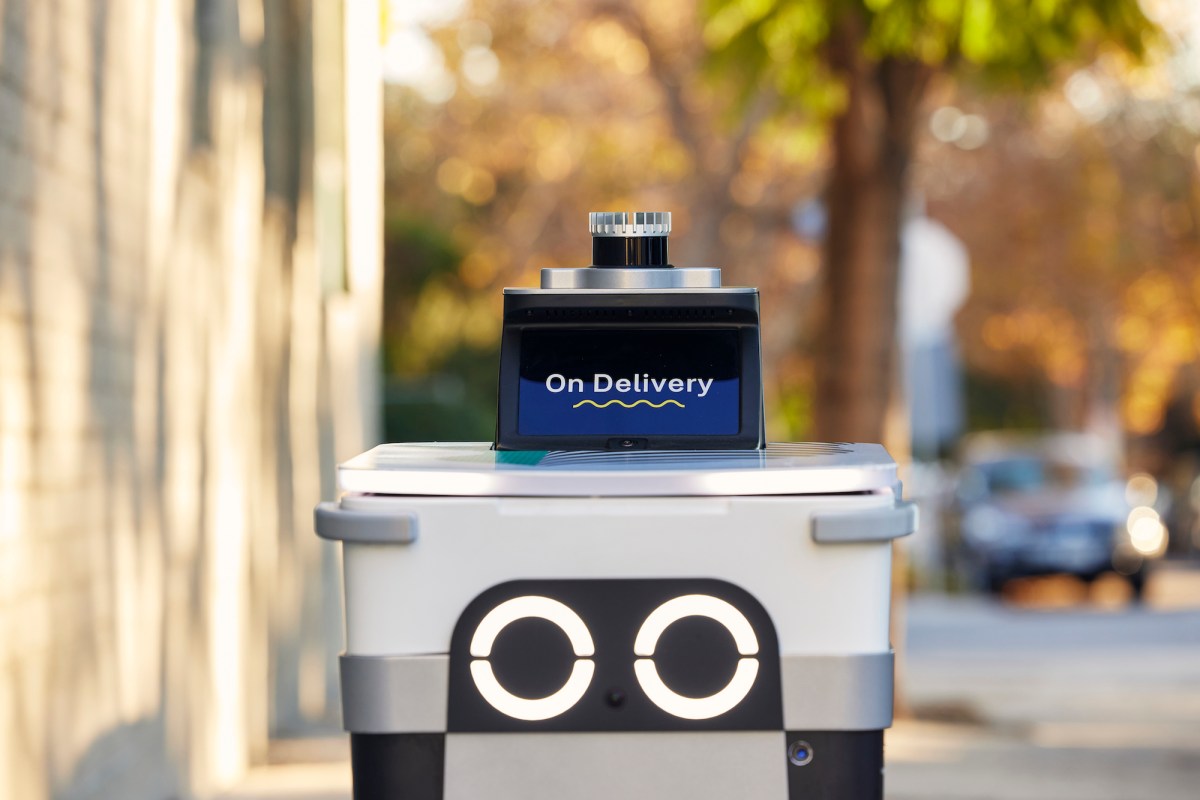
Serve Robotics launches new business to become the AWS for robots

Serve Robotics announced alonsgside its third-quarter earnings that it will launch a new business line called Physical AI Services to offer customers its connectivity and data tools.

Read at TechCrunch

Semiconductor Today SI

GaNrich providing 40–1200V GaN power device portfolio

Gallium nitride (GaN) technology firm GaNrich Semiconductor Corp of Zhubei City, Taiwan says that it has established a portfolio of 40V–250V low-mid voltage and 650V–1200V high-voltage GaN power devices on both GaN-on-silicon and GaN-on-sapphire wafer platforms, serving applications including AI data centers, battery backup units (BBUs), robotics, drones, electric vehicles (EVs), and on-board chargers (OBCs)...

Read at Semiconductor Today

Phys.org Space Space

NASA's Swift telescope has burned up, months after a robot sent to save it failed

NASA's Neil Gehrels Swift Observatory took its last look at the sky on Oct. 20, 2026, while orbiting about 171 miles (275 kilometers) above Earth. NASA ended the telescope's mission three days later, because Swift had sunk so low that drag from the thin air there meant its telescopes couldn't hold steady.

Read at Phys.org Space

Crunchbase News Judy Rider Startups

Sector Snapshot: Construction Robotics Funding Soars To $1.6B, Tripling Previous Peak

Companies spanning construction and robotics have raised about $1.6 billion so far this year — more than 4x the $389 million recorded in all of 2025 — according to Crunchbase data. The surge was driven by three companies that raised the…

Read at Crunchbase News

Ars Technica Jeremy Hsu SI

Agility Robotics' Nasdaq debut invites scrutiny of humanoid robot market

US leader in deploying humanoid robots goes public on the Nasdaq stock exchange.

Read at Ars Technica

TechCrunch Tim Fernholz SI

Agility is the first pure humanoid robot company on the stock market. Are you buying?

Agility arrives on the Nasdaq today as the first publicly-traded pure-play humanoid robotics company.

Read at TechCrunch

The New York Times Asia Adam Satariano

China Blocks SoftBank’s $5.4 Billion Robotics Takeover, Impeding Foreign Deals

Chinese authorities stopped the sale of ABB Robotics, owned by a Swiss conglomerate, to SoftBank of Japan amid wider scrutiny of global transactions that could affect Beijing’s technology ambitions.

Read at The New York Times Asia

Tech in Asia Diya Lal Startups

China blocks SoftBank’s $5.4b ABB robotics deal

SoftBank Robotics develops humanoid and service robots. SoftBank said the acquisition would broaden its industrial automation capabilities.

Read at Tech in Asia

eeNews Europe SI

HARTING unveils PCB connectors for AI robotics

HARTING will unveil new PCB versions of its Han Miniature Power Connector (MPC) at electronica 2026 in Munich, targeting humanoid robots and unmanned aerial vehicles (UAVs). The company will also showcase connectivity solutions for industrial automation, semiconductor manufacturing and AI infrastructure at the event, running November 10–13. The developments are relevant to electronics engineers looking

Read at eeNews Europe

MIT News AI Adam Zewe | MIT News SI

Clearing up a robot’s fuzzy memory

A new system identifies and corrects unreliable object descriptions stored in a robot’s memory, improving the robot’s ability to interact with its environment.

Read at MIT News AI

VnExpress International

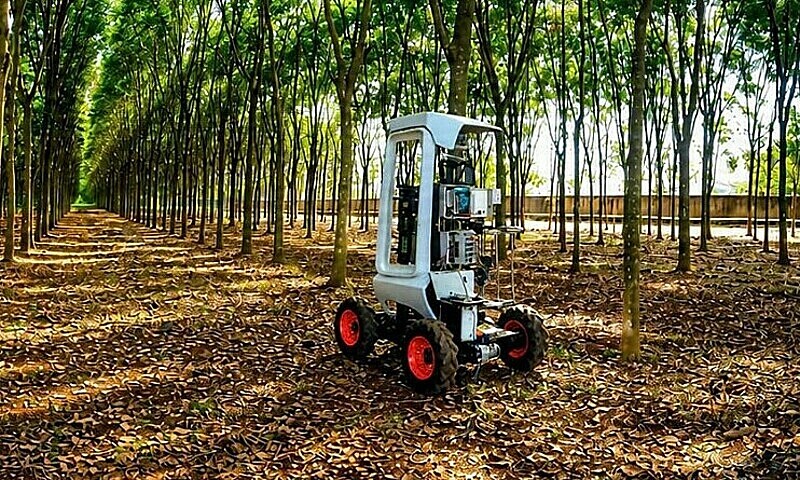
Vietnamese engineer builds rubber-tapping robot to replace human labor

A latex-harvesting robot developed by engineer Do Minh Tam can perform hazardous plantation work 50% faster than a skilled tapper.

Read at VnExpress International

Tech in Asia Aiko Gao Ishida Startups

Baidu unveils AI world model to train, test robotaxis

Baidu said Apollo Go operates in 28 cities and had provided more than 23 million rides as of June 2026.

Read at Tech in Asia

GeekWire Todd Bishop SI

Zillow CEO’s reality check on AI agents: ‘Finding a home isn’t a chore to hand off to a robot’

Zillow Group CEO Jeremy Wacksman said Wednesday that most people won't want AI agents doing their house hunting, even as they hand off tasks like canceling subscriptions. The question matters for Zillow, which makes most of its money when…

Read at GeekWire

Graham Cluley Graham Cluley Security

Smashing Security podcast #491: How AI agents are spooking the banks

Bank of America has a message for its customers: please, for the love of God, stop handing your banking passwords to your AI assistant. And if your robot does something daft with your money? That's your problem, not theirs. Meanwhile, a company that promised to rescue ransomware victims without paying the criminals stands accused of... paying the criminals. ProPublica's Renee Dudley was on the case years before the indictment. Plus, Dropzone AI's Edward Wu asks what happens…

Read at Graham Cluley

Journal articles (OpenAlex) Ioannis Giachos, Nikoletta E. Samaridi, Ευάγγελος Χρήστος Παπακίτσος et al. · Artificial Intelligence and Applications

Designing a Small Language Model Lexicon in Natural Language for Robotic Applications

In this paper, the aim is to present a project report of a method, based on which a small natural language lexicon is designed, or otherwise a small language model, for robotic applications. In this direction, a reference is made to Controlled Natural Languages, and their characteristics are determined for application in operational robotic vehicles. In addition, criteria are established for the selection of the nationality of the language, which constitutes the basis of the…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Antonia Georgopoulou · Advanced Materials Technologies

Organoids as Building Blocks for Adaptive and Resilient Biohybrid Robots

ABSTRACT Biohybrid robots combine engineered living tissues with synthetic materials and have emerged as a promising class of soft robotic systems capable of mimicking biological functions such as biodegradability, energy efficiency and flexible motions. By integrating biological and synthetic components, these systems leverage complementary properties to perform key robotic functions including locomotion and task execution. Despite rapid progress, important limitations…

Read at Journal articles (OpenAlex)

Older stories