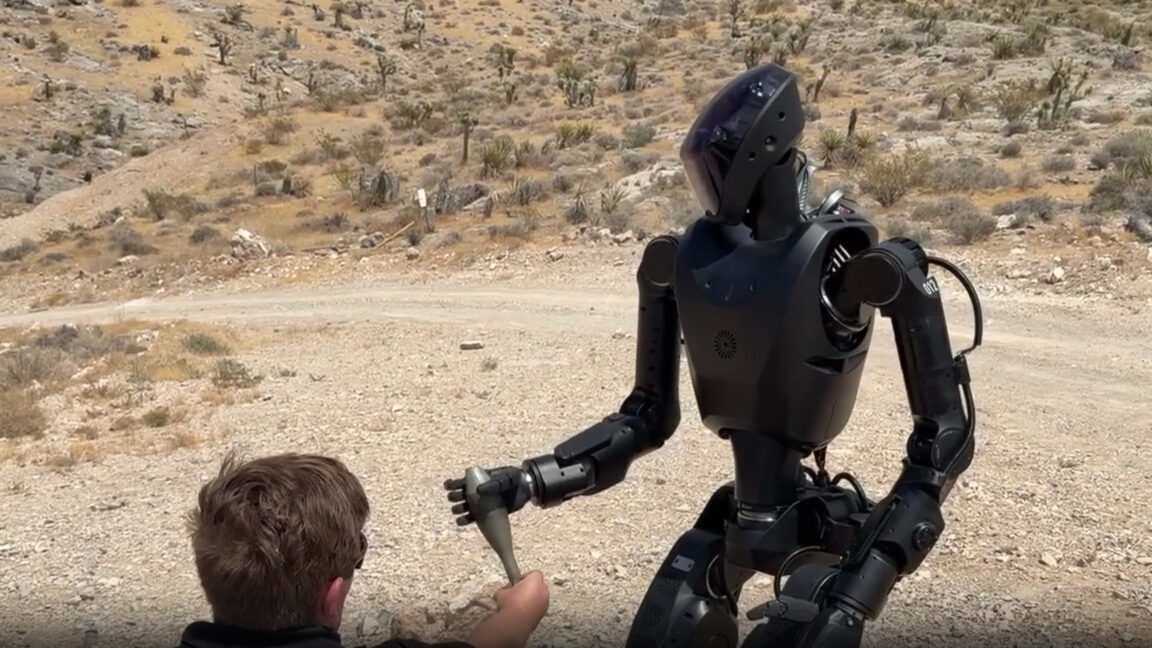
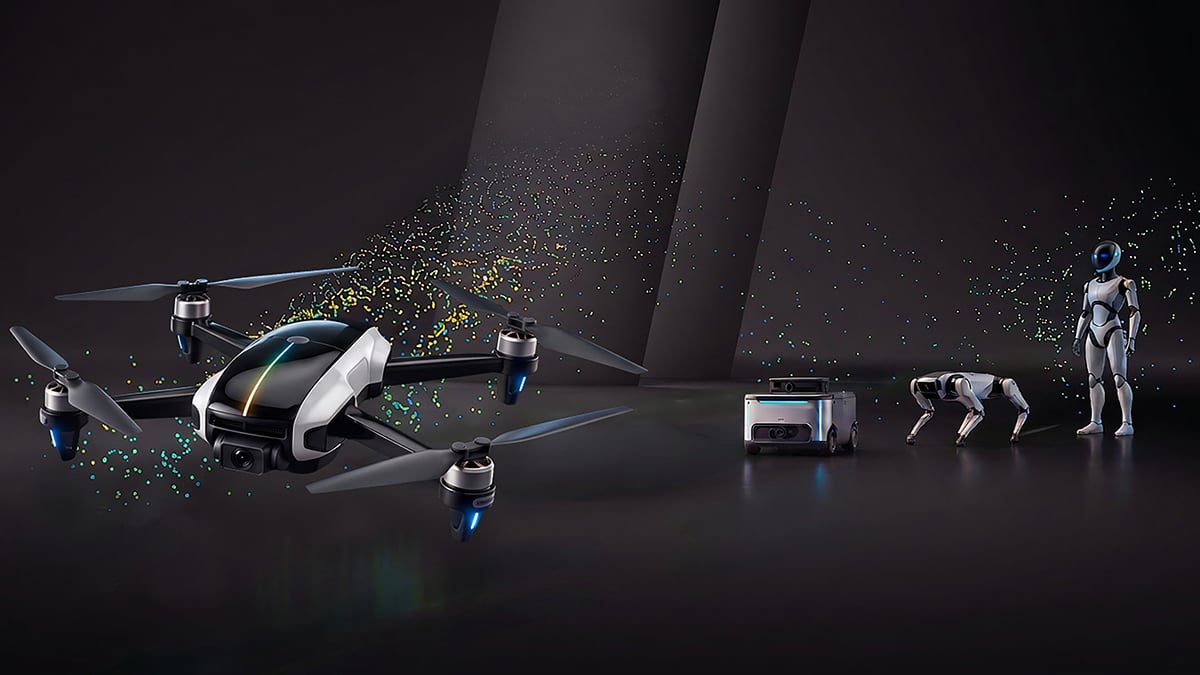
China’s robot makers have more to offer than viral backflip videos
Established robotics companies are continuing to grow and many are highly profitable
Established robotics companies are continuing to grow and many are highly profitable
General-purpose behavior models increasingly internalize broad procedural knowledge during training, making their adaptation to new goals and skill interfaces less a problem of learning entirely new behaviors than of reconfiguring existing competence. We study this capability as reconfigurability, the ability to realize new behaviors by cost-efficiently restructuring existing components and relations under sparse governing information, where task specifications provide…
WeRide has approval for a paid, fully driverless robotaxi service in Guangzhou's Huangpu District.
Multimodal agents can now control robot arms by calling tools and writing code. Existing benchmarks fall short in three ways: most test one or two arms on short tasks, many pause the world while the agent thinks, and many give it ground-truth object positions. We present RoboTeam, a simulated benchmark where agents control 4 to 16 robot arms in real time from camera images alone. Its 36 tasks are long jobs that the arms must do together, such as passing timbers or building a…
Sidec said 20 companies at the IC Design Park had hired 432 fresh engineers.
Robotics startup misses payroll a year after CEO used funds for luxury home.
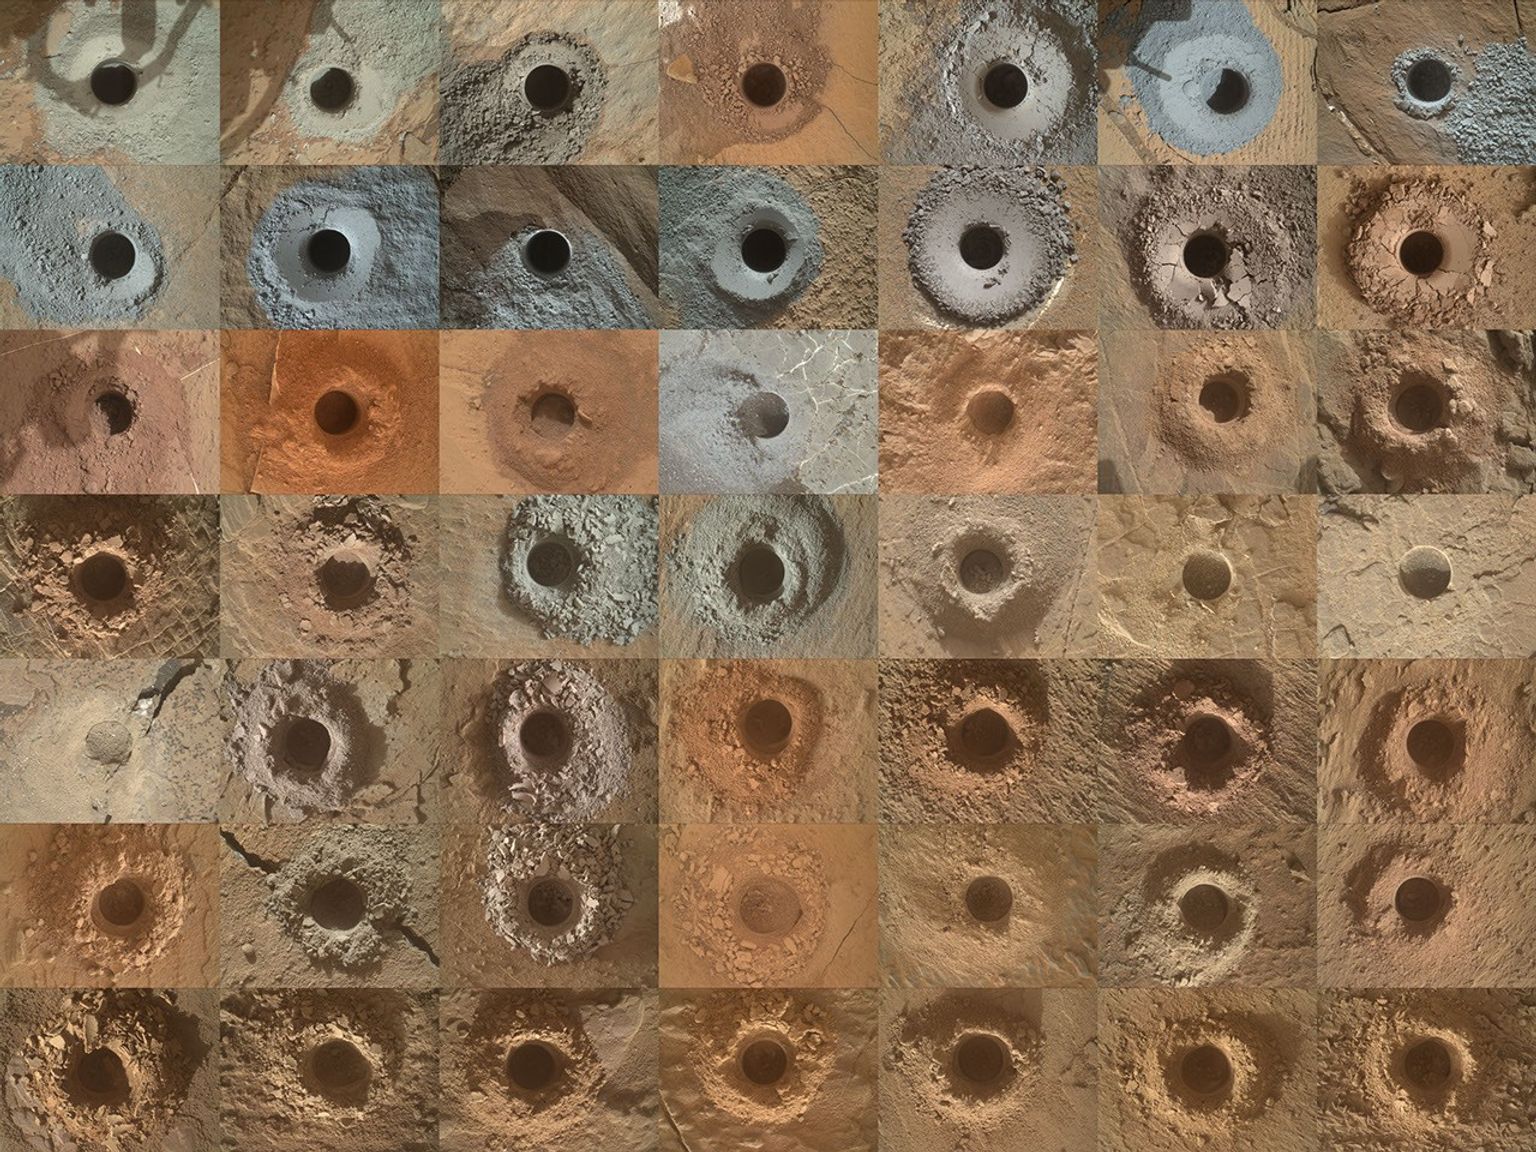
Description This collage shows 49 drill holes captured by NASA’s Curiosity Mars rover as of November 2026. Each hole represents a sample collected from rocks on the Martian surface; Curiosity’s drill, located on the end of its robotic arm, drops pulverized rock samples into instruments in its belly that analyze their composition. These images were
Frontier Vision-Language Models (VLMs) such as GPT-6 Astra have demonstrated remarkable capabilities in robot control, suggesting that broad pretraining provides knowledge valuable for physical action. Yet most Vision-Language-Action (VLA) policies still rely on much smaller VLM backbones, leaving this potential largely untapped. We ask whether frontier-scale representations can provide a stronger foundation for robot learning. We introduce ScaleVLA, which connects a 552B…
Long-horizon manipulation tasks require a robot to perform a sequence of physical interactions with its environment, typically combining several different skills. Planning such behaviors efficiently is challenging: given a library of parameterized skills, solutions lie in a vast hybrid space of skill sequences and their parameters, and evaluating each candidate skill's feasibility and effect with a high-fidelity world model such as a physics simulator is computationally…
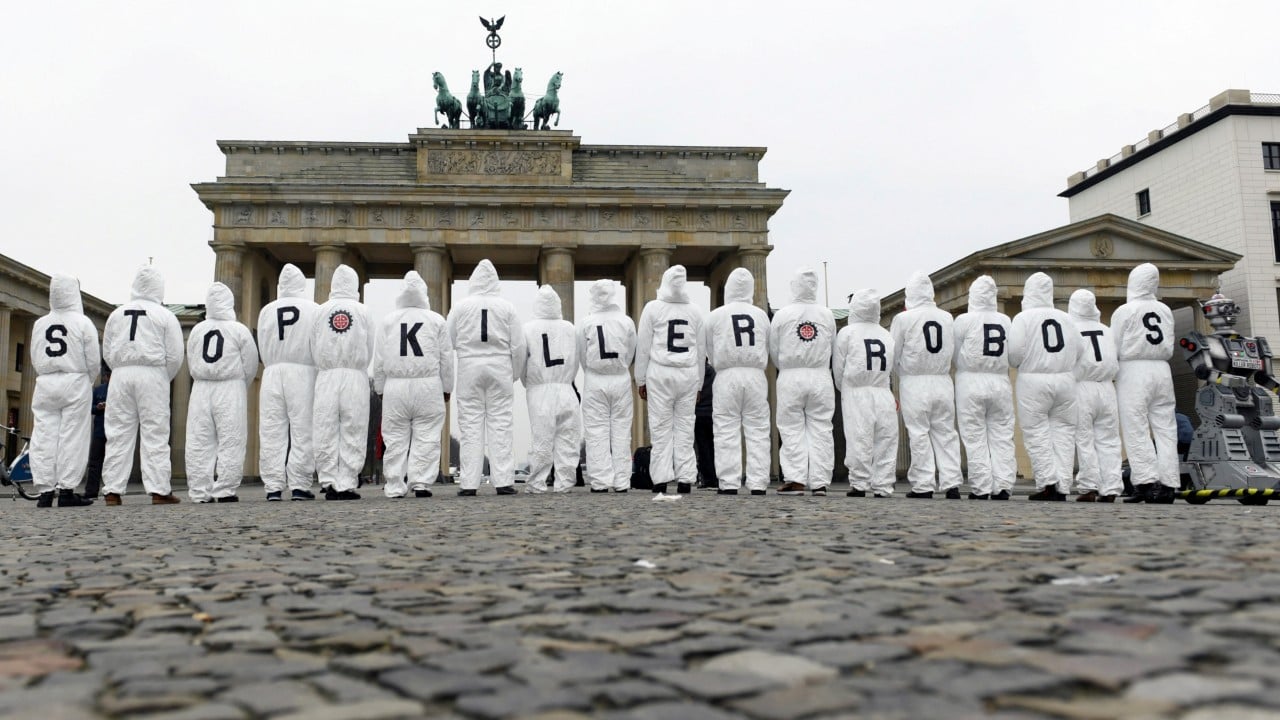
Countries are meeting in Geneva to negotiate rules on weapons that can select and kill targets without human intervention. But with the U.S., Russia and Israel resisting legally binding controls, campaigners fear the window to act is closing.
All-electric heavy-duty robotic manipulators are increasingly expected to operate close to tunnel walls, equipment, and other structures while retaining the force capability required for large-payload tasks. Accurate motion control alone does not address the resulting safety and interaction requirements. This paper develops a safety-aware physical-interaction architecture that combines variable impedance control (VIC) with control barrier functions (CBFs) on top of an…
Learned physics-based models provide structure for robot control, but uncertain payloads and unmodeled dynamics limit their predictive accuracy. Context-aware Deep Lagrangian Networks enable adaptation through a latent context inferred from measurement histories while retaining Lagrangian structure for each fixed context. However, this structure alone does not constrain sensitivity to measurement disturbances. We introduce BoBDeLaN, which combines a contracting, gain-bounded…
Cooperative mobile manipulation requires robots to coordinate their motions while ensuring whole-body collision avoidance and preserving task-relevant behaviors. We propose CALDS (Cooperative Adaptation of Learned Dynamical Systems), a framework that enables mobile manipulators to adapt learned single-agent behaviors for coordinated execution. Building on individual dynamical systems (DSs) learned from demonstrations, CALDS enables cooperative adaptation through two key…
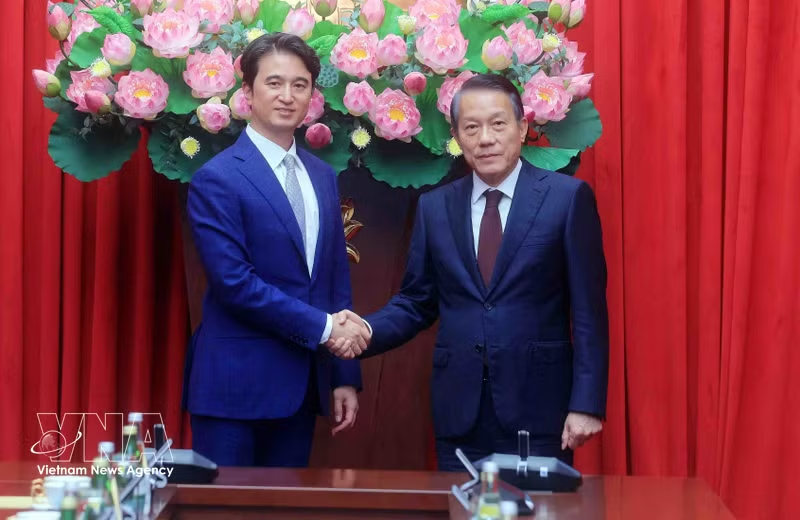
Minister of Public Security General Luong Tam Quang called on the RoK's SK Innovation to share experience and work with Vietnamese partners in developing clean and renewable energy, hydrogen, liquefied natural gas, energy storage technologies and carbon emission reduction solutions. Vietnam, RoK seek to expand cooperation in AI and semiconductor sectors Vietnam, RoK cooperate in robot industry Vietnam, RoK see ample room for cooperation in energy, offshore services
Robots, vehicles, and wearable devices often traverse the same environment many times. Each pass produces its own trajectory from onboard visual or visual-inertial odometry. These trajectories are locally accurate but drift over time and live in unrelated coordinate frames. Turning many such independent trajectories into one globally consistent set is the large-scale multi-session trajectory optimization problem. Existing solutions largely work offline. All sessions must be…
Human manipulation data are widely used to train robots for human-like dexterity. However, low-cost, large-scale collection in the wild remains challenging. Existing methods remain limited in geometrically grounded metric-scale reconstruction, real-world generalization and inference speed. We present WinDEX, integrating (1) geometric-temporal optimization for metric 3D hand annotation from in-the-wild egocentric stereo videos, combined with visual-inertial SLAM for…
DoorDash Labs engineers are using Amazon Web Services to pack all the capabilities of an autonomous car into a robot a fraction of the size.
I am practicing brain surgery on a patient lying 6 meters away, out of my sight and reach. I press a foot pedal, activating the controller in my hand, and carefully steer a thin flexible tube called a catheter up through the patient’s blood vessels. I head for what I believe to be the brain, tracking my progress on the live X-ray feed. As I imagine finding a blood clot, David Bell, the surgeon seated to my right, helpfully reminds me that every minute a stroke goes…
Robots that work alongside people should be able to use what they have seen when new requests arise. The same experience may later support identifying an object or returning it to its original location, although these uses were unknown during observation. ReuseMem learns to use one visual memory for multiple later manipulation goals. It records visual features independently of future goals, retrieves complementary evidence for each request, and combines it with the current…
Frontier multimodal models can now control robots zero-shot from images, yet many manipulation tasks depend on contact forces that images cannot show. Bringing force to an API-only frozen model raises two challenges. First, contact evolves much faster than an API model can decide, so the system must close the loop on force beneath the model. Second, a frozen model cannot interpret raw force streams, so force must be returned in a form the model can reason about. Therefore…
NXP Semiconductors is seeking to reduce the time and complexity involved in developing autonomous robots with a new hardware and software platform that brings together artificial intelligence, motor control, connectivity and security. The Dutch semiconductor group unveiled its unified robotics platform at electronica 2026, positioning it as a way for developers to move from evaluating…
Dynamical-system-based motion policies provide a framework for learning reactive robot motions with stability and convergence properties. Many manipulation tasks, however, admit several distinct goals or a continuous set of acceptable outcomes, requiring motion primitives that preserve these alternatives. Accommodating both goal structures within a unified framework with continuous, autonomous dynamics remains an open challenge. We propose a CONDOR-based framework…
Autonomous monitoring and intervention in semi-structured agricultural environments, such as orchards and vineyards, require mobile robots to navigate to locations across diverse field configurations. This entails performing navigation behaviors including in-row driving, row turning and skipping, and inter-row traversal. Recent learning-based approaches have enabled robust in-row navigation from onboard perception, but navigation across rows typically requires a priori…
Inverse kinematics are critical in many robotic applications, yet standard MoveIt-based solvers struggle in confined scenarios. This paper provides a benchmark of the available solvers and compares multiple practical modifications for improving the performance of the solvers. Splitting the IK problem into two parts results in the best performance, leading to a 100% success rate under 100 ms in an endoscopic tank scenario.
This is the first time Amazon-owned Zoox has partnered with a ride-hailing platform.
Uber may be breaking up with Waymo, but it's also gaining a new robotaxi BFF: Amazon. Starting today, Uber riders in Las Vegas can be matched with Amazon-owned Zoox's purpose-built, bidirectional robotaxis. It's a first for both companies: the first time Uber is adding a purpose-built, steering-wheel-free autonomous vehicle to its network, and the first
Natural, coherent full-face dynamic expressions are central to making humanoid robots socially approachable, yet existing systems commonly realize only limited lip motion or scripted expressions. The limitation is both physical and algorithmic. A compact head leaves little room for densely packed, independently controllable actuation; meanwhile, learned systems often generate an avatar video, landmarks, or facial parameters and then infer actuator commands through visual…
Optical tactile sensors record tactile videos that capture local deformation and its temporal evolution during contact, supporting robot manipulation, force estimation, and tactile representation learning. Differences in imaging geometry, background appearance, illumination, resolution, and deformation response lead to sensor-dependent observations of the same contact across GelSight, DIGIT, GelSlim, TacTip, and other optical tactile sensors. This variability limits…
The United Nations chief called on countries on Monday to impose binding rules on the use of “merciless” lethal autonomous weapons systems, often dubbed “killer robots”, on the battlefield. Warfare is undergoing a radical transformation as armies seek to capitalise on artificial intelligence to boost their fighting abilities by identifying and striking targets more quickly and accurately. Amid a chorus of warnings against handing the power of life and death to autonomous…
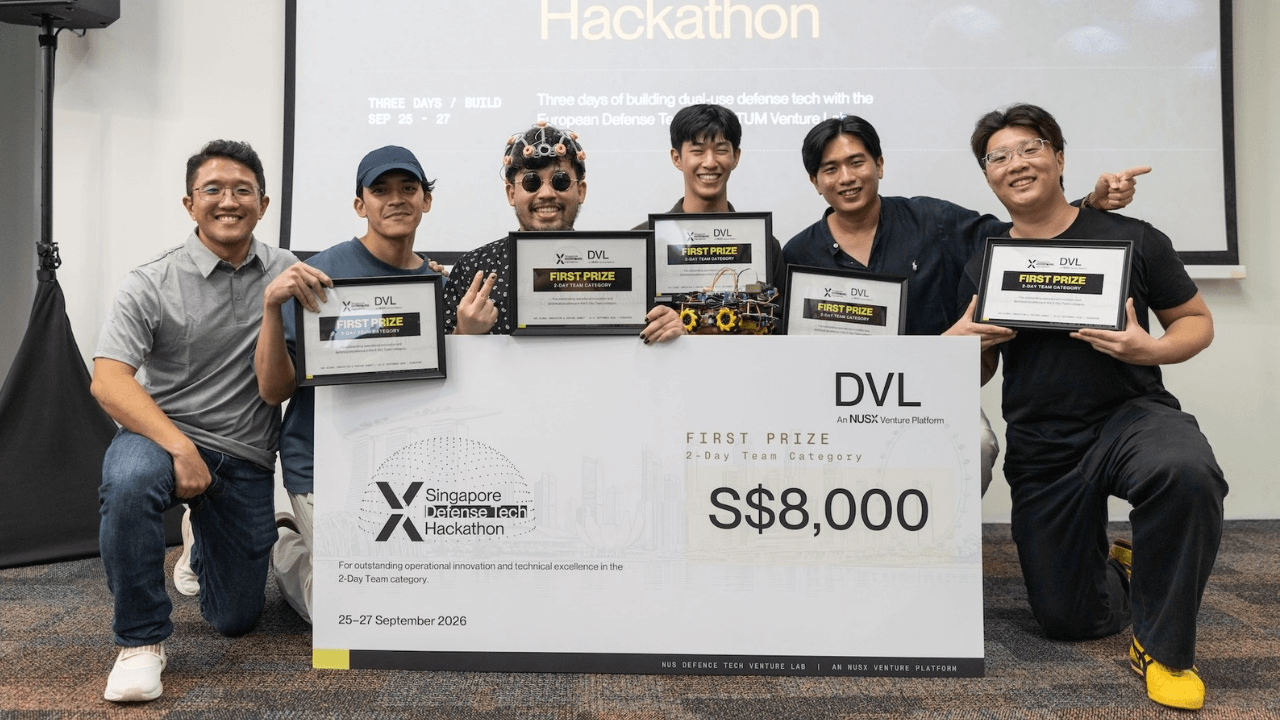
The past few years have seen a resurgence of hackathons and hacker houses, alongside growing interest in robotics, hardware and the software powering them. The European Defense Tech Hub (EDTH) is part...