Results for “Robot”

NVIDIA Blog Sasa Docca SI

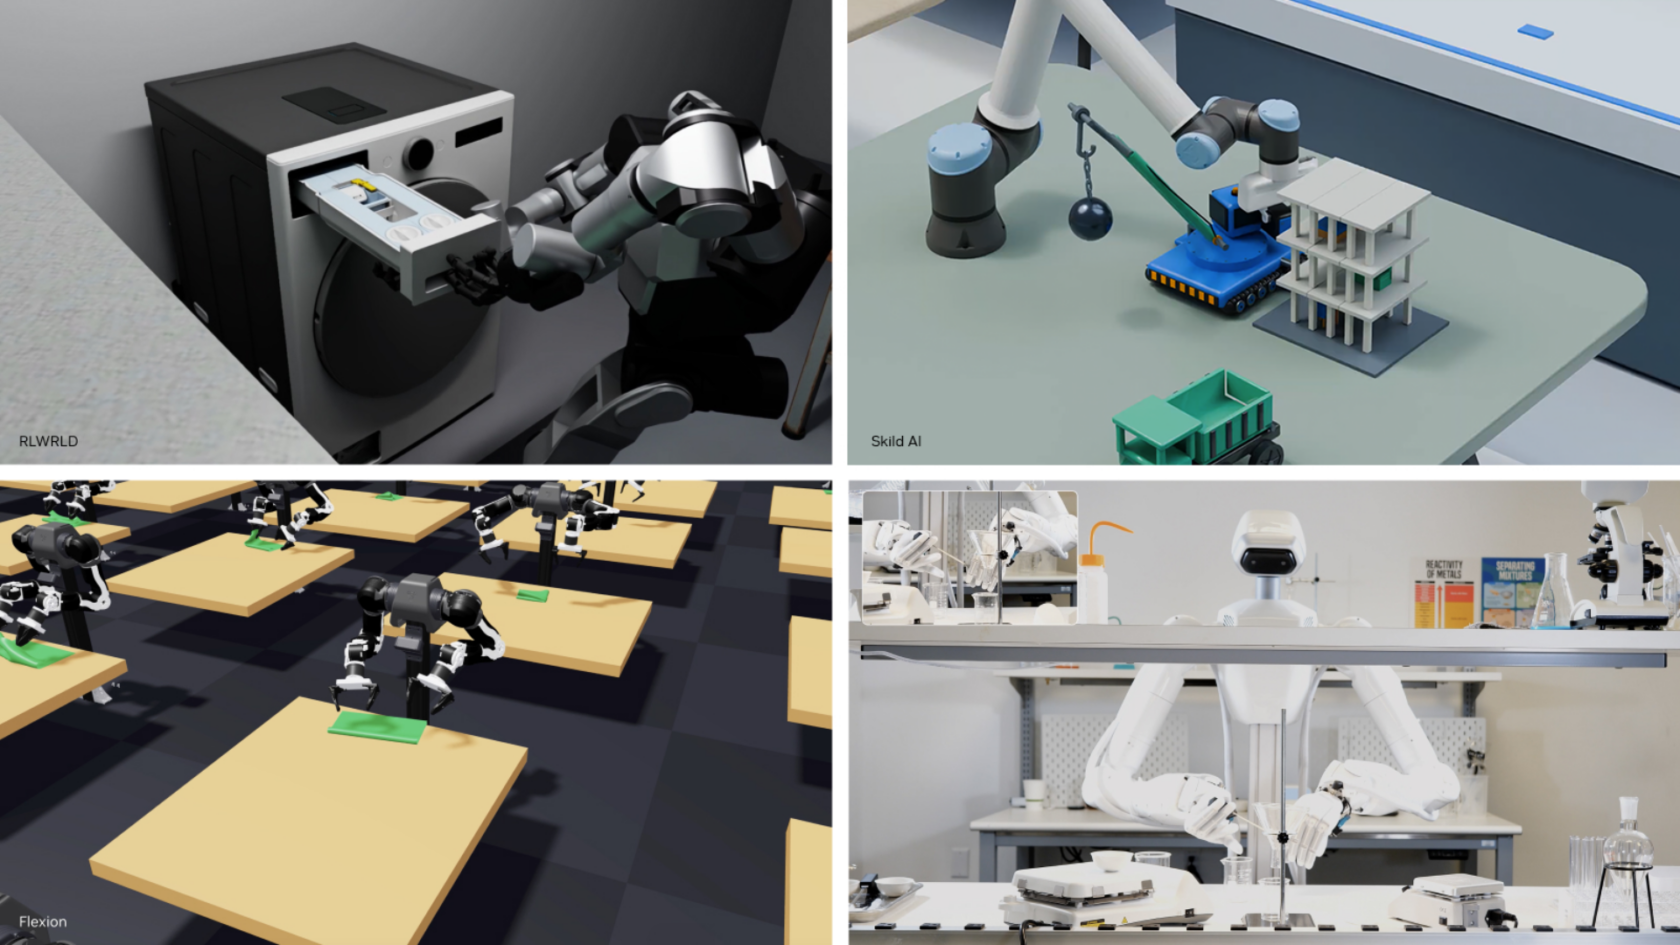
Practice Makes Precise: At CoRL, NVIDIA and Partners Reveal How Robots Rehearse Delicate Work in Simulation

Simulation, which has long been the proving ground for robots learning to walk, roll and hop, is now helping researchers teach robots tasks that require a finer touch: aligning gears, connecting cables and assembling small components. The shift from locomotion to manipulation is taking center stage at this week’s Conference on Robot Learning (CoRL) in
Read at NVIDIA Blog

The Hacker News Security

⚡ Weekly Recap: SSHole Exploited, APT Root RCE, Robot Takeovers, 15K Hacked Sites, and More

A system doesn't always need a complicated bug to let someone in. Sometimes, a blank password is enough. That's one of the bigger stories this week. And it gets worse when the tools meant to keep systems updated or running safely become part of the attack. Elsewhere, attackers are hiding inside normal web traffic, stealing credentials from network devices, and finding new uses for exposed

Read at The Hacker News

TechCrunch Kirsten Korosec

Tesla expands robotaxi service to San Antonio

This will be the fourth Texas city in which Tesla will launch robotaxis.

Read at TechCrunch

Hackster.io Gareth Halfacree https://www.hackster.io/ghalfacree

NXP Unveils Its Unified Robotics Platform, Complete with Ready-in-30-Minutes Drone Reference Design

New platform will cover everything from drones to, in a future release, autonomous mobile and humanoid robots, NXP says.

Read at Hackster.io

WIRED Ritsuko Kawai

These Robotic Arms Are Powered by Algae. Watch How They Move

The key to the movement of these flexible robots is the algae’s photosynthetic capabilities.

Read at WIRED

Axios Zachary Basu Geopolitics

Elon Musk's empire braces for Democratic crackdown

Elon Musk's sprawling empire — from rockets to robots, electric cars to AI — is facing a political onslaught with few parallels in modern corporate history. Why it matters: The world's richest man confronts a constellation of risks spanning the halls of Congress, his Texas industrial empire, Wall Street and his vision for AI supremacy. 💰 Political: To Democrats, Musk embodies corrosive forces of the MAGA era — extreme wealth, billionaire influence over government, the…

Read at Axios

Hackster.io Gareth Halfacree https://www.hackster.io/ghalfacree

Renesas Targets Robotics and Industrial Equipment with Its New RZ/T2N Quad-Core Chip

Microprocessor combines motor and encoder interfaces with industrial Ethernet support, two application-class cores, and two real-time cores.

Read at Hackster.io

Tech in Asia Diya Lal Startups

China’s UBTech, Tianyi team up to scale humanoid robot market

The firms also aim to help biomimetic and wheeled humanoid robots surpass 100,000 units.

Read at Tech in Asia

Berkeley AI Research blog SI

BAIR at CoRL 2026

The Conference on Robot Learning (CoRL) takes place November 9–12, 2026, in Austin, Texas. BAIR faculty, postdocs and students will be presenting research at various sessions, including an Early Career Keynote from Professor Negar Mehr. See below for the full schedule of sessions with BAIR members, including papers co-authored with collaborators at other universities and companies. November 9–12, 2026Austin, TexasAll times CST · UTC−6 33Main-conference papers 4Late-breaking…

Read at Berkeley AI Research blog

Future Farming René Koerhuis

Finite Robotics to solve labour and knowledge gap in apple thinning

Finite Robotics is developing a robotic thinning solution for apple orchards in particular. Their Robothinner is intended to be used in addition to common thinning methods.

Read at Future Farming

Future Farming Geert Hekkert

Who is to blame if an agricultural robot kills someone?

Autonomous tractors and robots are gradually making their way onto farms. There are several reasons why we are unlikely to see a massive wave of adoption just yet. One is the uncertainty surrounding legislation and liability. After all, what happens if a driverless tractor causes a fatal accident? Who is responsible? The farmer, the manufacturer or the software developer? This is a question the agricultural industry will be grappling with for years to come.

Read at Future Farming

EE Times Sally Ward-Foxton SI

DeepX Tapes Out Second-Gen Chip, Projects 6.7× Performance Gain With LPDDR5x-PIM

DeepX is targeting edge markets including robotics with its second-generation AI accelerator, which can run large LLMs on device in under 5 W.

Read at EE Times

NVIDIA Blog NVIDIA Writers SI

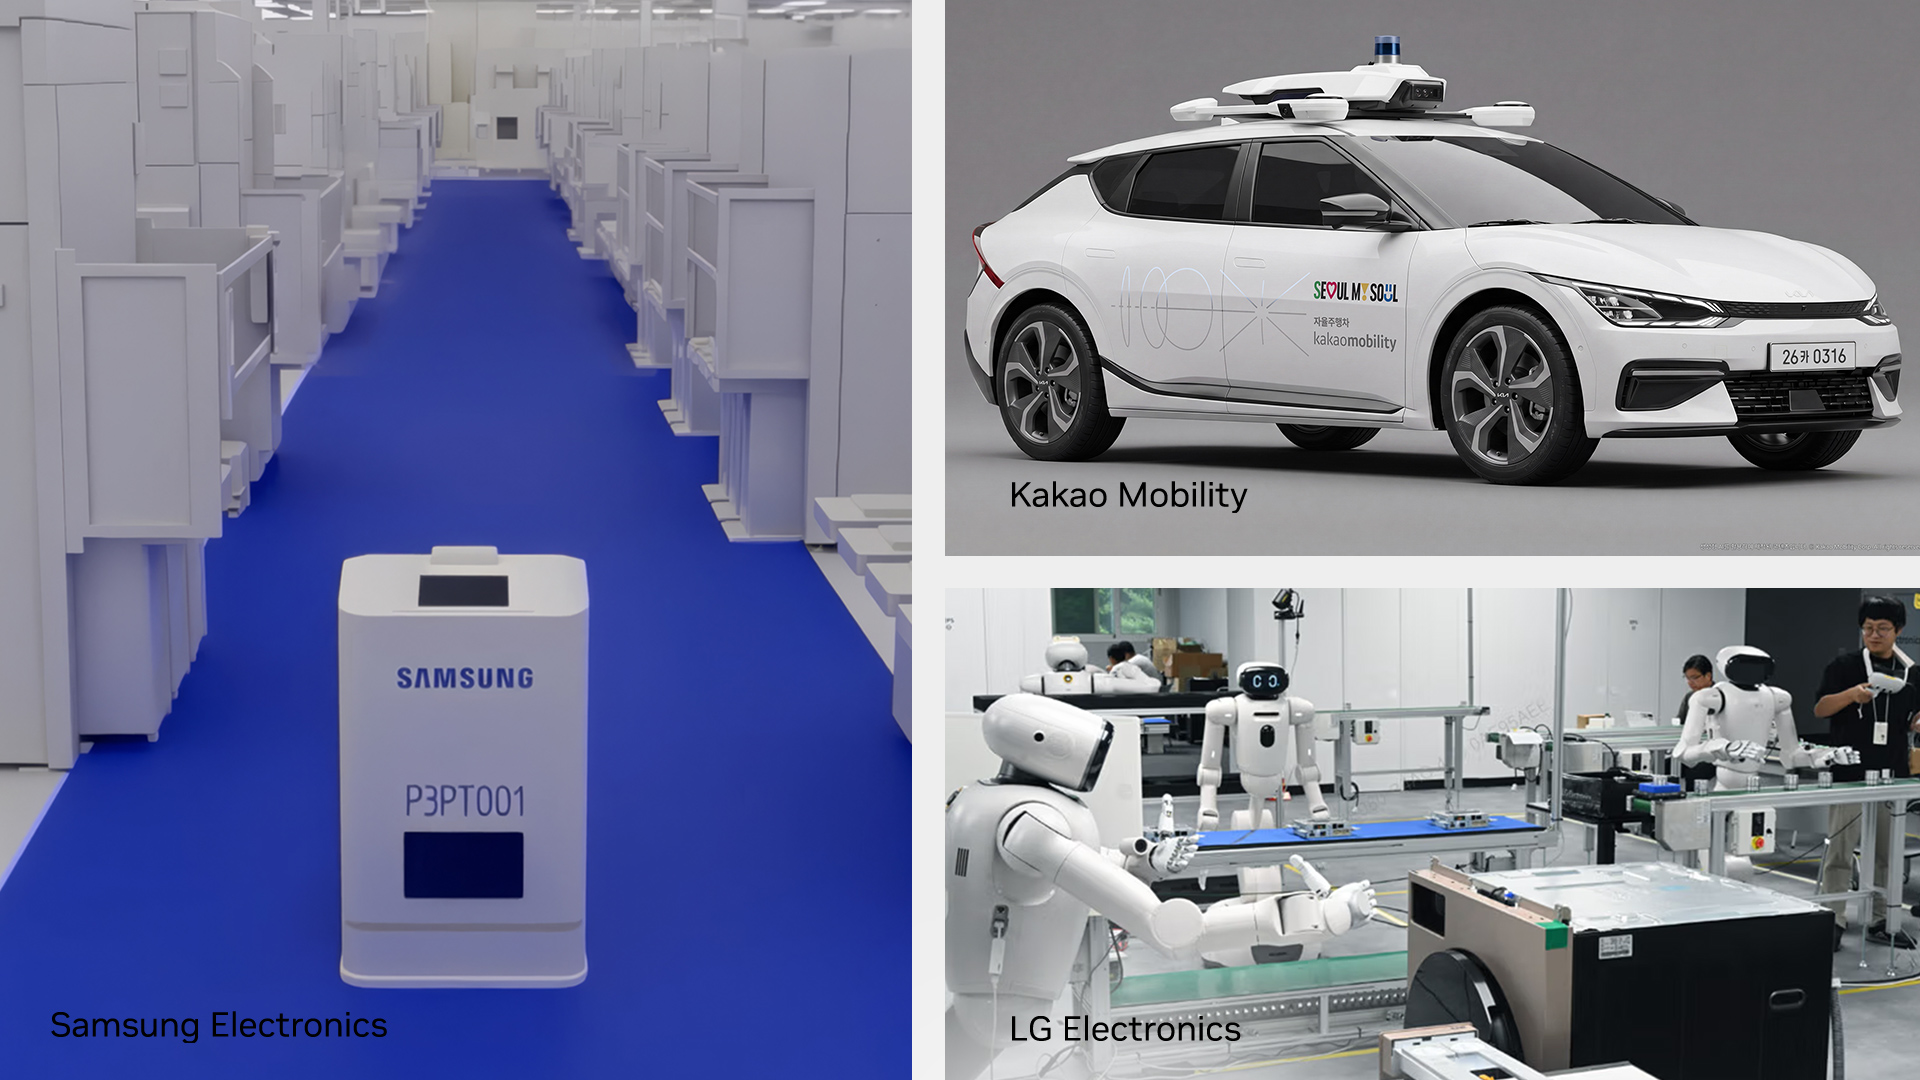
Korea Advances Physical AI Across Industries With NVIDIA

Tapping into the country’s strengths in manufacturing and engineering, NVIDIA is helping advance Korea’s physical AI ecosystem. The country’s industry leaders are applying accelerated computing, AI and simulation to everything from semiconductor manufacturing to robotics and autonomous vehicles. These efforts are helping bring physical AI from development into real-world production. Samsung Advances Semiconductor Engineering With

Read at NVIDIA Blog

MIT News AI Jennifer Chu | MIT News SI

AI-assisted learning platform helps robots reason beyond literal commands

The new approach, known as FLEX, could lead to more intuitive, interactive household and assistive robots.

Read at MIT News AI

MIT News AI Adam Zewe | MIT News SI

A single AI model simulates the behavior of many substances, from sliding sand to folding proteins

By learning how matter moves, the WorldParticle system could assist with developing soft robots, medicines, and more.

Read at MIT News AI

Journal articles (OpenAlex) Monika Hromasová, Albert Suchopár, Miloslav Linda et al. · Technologies

A Review of Software Architectures, Communication Protocols, and Edge Intelligence for Modular Agricultural End-Effectors

Year-round utilization of agricultural robotic platforms requires adaptable systems capable of performing multiple operations with interchangeable end-effectors. Although mechanical tool-changing mechanisms are well established, software interoperability, communication, and adaptive perception remain challenges. This narrative review examines software architectures, communication protocols, and edge intelligence technologies relevant to modular agricultural end-effectors…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Xiaohan Liu, Ziwu Ren, Yunxi Miao et al. · International Journal of Robust and Nonlinear Control

Sliding Mode Controller Design for Robotic Manipulator Based on the Hybrid Pigeon‐Inspired Optimization

ABSTRACT To address the challenge of finding the optimal parameter combination for proportional–integral sliding mode (PISM) controllers in robotic manipulators, this article proposes a novel hybrid pigeon‐inspired optimization (HPIO) algorithm for systematic parameter tuning. The proposed algorithm enhances the conventional PIO framework by incorporating a predation‐inspired random perturbation mechanism and a dynamic population screening strategy, thereby balancing global…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Bartosz Bieńkowski, Wojciech Kaczmarek · Sensors

Recognition, Stabilization, and Command-Mapping Algorithms for Contactless Hand-Gesture Control of an ABB Industrial Robot

Although contactless hand-gesture interfaces can support intuitive human–robot interaction, transient classification errors may trigger unintended commands when classifier outputs are mapped directly to robot actions. This study presents a processing framework for contactless control of an ABB IRB 120 industrial robot. The framework combines RGB acquisition, geometric normalization of 21 MediaPipe hand landmarks, population-based sample filtering, multilayer perceptron…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Manuel J Heredia-Rios, Enrique Pérez‐Gutiérrez, Francisco Domingo Calvo López et al. · The International Journal of Advanced Manufacturing Technology

Integration of an ABB YuMi collaborative robot and a CNC doctor-blade coater into an event-driven cyber-physical manufacturing workcell

Abstract This work presents an event-driven cyber-physical manufacturing workcell that integrates an ABB YuMi collaborative robot with a computer numerical control (CNC) doctor-blade coater for laboratory-scale thin-film processing. Both subsystems retain their local motion-control routines, while Node-RED acts as the supervisory layer and coordinates process progression through high-level commands and reported execution states. Communication is implemented through a hybrid…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Changjian Wang, Zhang Tianyou · Frontiers in Psychology

Empirical study on how lower limb exoskeleton robots improve older adults’ physical performance through psychological mechanisms

Objective This study aims to explore how lower limb exoskeleton robots enhance physical performance in older adults and clarify the mediating role of psychological factors during human-robot interaction exercises. Methods The study focused on healthy older adults in the community and used a randomized controlled trial design along with qualitative research methods. A total of 60 participants aged 60–75 were selected and divided into an lower limb exoskeleton robots…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Raveeroj Bawornkitchaikul, Ruikang K. Wang, Matthew O’Donnell et al. · Biomedical Optics Express

DINOCT: robust skin surface localization for robotic noncontact dynamic optical coherence elastography

Noncontact dynamic optical coherence elastography (OCE) can measure the elastic properties of anterior soft tissues. However, applying OCE to skin requires tracking mechanical waves propagating in multiple directions to reconstruct mechanical anisotropy. Robotic scanning is well suited to this task but requires accurate probe positioning, alignment to the surface normal, and precise, repeatable rotation. To ensure phase and polarization stability, polarization-maintaining…

Read at Journal articles (OpenAlex)

arXiv (research papers) Hongyu Luo

Compute Regeneration through Re-Productization: Reorganizing Retired Edge AI Silicon into a Delivered Multilingual Service Robot

Useful edge hardware can lose product support while retaining substantial computation. We treat this as systems design: compute regeneration here means re-productization, retaining the compute module while redesigning the surrounding product organization. Our case is GEdgeBot, a multilingual service robot built around a retired 32 GB Jetson AGX Xavier. A source-grounded inventory shows the box alone supplies inference, while the combined system exposes five on-device AI…

Read at arXiv (research papers)

arXiv (research papers) Yiming Sun SI

When Coding Agents Get Arms: Safety Risks Across the Digital-Physical Boundary

Advances in spatial understanding have enabled frontier models to power coding agents that control a real robot arm zero-shot and end-to-end, without task-specific demonstrations or retraining. This brings two new safety challenges. First, the extensive knowledge of frontier models lets these agents perform tasks that earlier VLA and WAM paradigms could not, opening the door to new forms of capability misuse. Second, coding agents can access digital resources such as web…

Read at arXiv (research papers)

WIRED Reece Rogers SI

World Models Will Soon Be Inescapable. Here’s What You Need to Know

Moving AI from text to 3D space, world models simulate real-world physics to teach robots and autonomous cars how to navigate reality.

Read at WIRED

arXiv (research papers) Zhengyang Cheng

Efficient VLA Inference via Retrieval-Based Speculation and Hardware Acceleration

Vision-language-action (VLA) models enable robots to understand and execute complex instructions, but their autoregressive (AR) action generation introduces significant latency on resource-constrained robotic platforms. Speculative decoding can accelerate AR-based inference by parallelizing action generation and verification; however, existing approaches rely on costly draft models, which are inefficient on edge platforms. In this paper, we propose Zora, a hardware-software…

Read at arXiv (research papers)

Journal articles (OpenAlex) Minyang Wang, Bangcheng Zhang, Zhi Wei Gao · Mathematics

An Uncertainty-Adaptive Robust Graph-Based Belief Rule Base for Interpretable Four-State Fault Diagnosis of Industrial Robots

Industrial robot severity diagnosis must combine evidence from coupled subsystems while remaining stable under fluctuating measurements. We develop an uncertainty-adaptive robust graph-based belief rule base (RG-BRB) that maps monitored attributes to transmission, servo-control, and motion-execution nodes. A row-stochastic graph propagates node evidence, while local fluctuation adjusts antecedent widths and attribute reliability before rule activation. Normalized evidential…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Shih‐Hao Chang, Minyechil Alehegn Tefera, Jun-Ming Cheng et al. · Sensors

Vision-Guided Robotic Arm with Deep Learning and Secure Digital Twin for Pre-Deployment Quadruped Robot Operation

In this article, we propose a vision-guided robotic arm system that integrates deep learning, digital twin, and cybersecurity to enhance the maintenance of quadruped robots. The proposed system comprises two core components. (1) A YOLOv11-based object detection system with depth cameras identifies maintenance targets and extracts 3D coordinates for autonomous robotic arm localization and manipulation. (2) A digital twin environment is used to simulate and validate path…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Minsu Kim, Hoyeon Cho, Sungkeun Yoo et al. · Sensors

Magic-Formula-Based Feedforward Velocity Control of a Magnetically Coupled Wall-Climbing Robot

This study presents a model-based feedforward method for reducing velocity errors during the vertical travel of a magnetically coupled wall-climbing robot. Permanent magnets on opposite sides of the wall maintain magnetic coupling, while a spring-preloaded linkage adjusts the drive-wheel normal force. A dedicated test bench was used to measure the traction–slip characteristics of the urethane roller–acrylic contact at normal forces of 20 and 30 N. Magic Formula models were…

Read at Journal articles (OpenAlex)

Older stories