User review: Will field robots become the next milking robots?
User review: Will field robots become the next milking robots? Can autonomous field robots become
User review: Will field robots become the next milking robots? Can autonomous field robots become
In the 1990s, Sony was absolutely convinced that we were on the precipice of a robot takeover. Pretty soon, the company decided, we'd all be living among countless humanoid robots. Some would be our coworkers; others would be our friends; and at least one would be our pet. And "pet" was exactly what Sony was
Real-time whole-body imitation from monocular video requires both a robust universal tracker and high-quality real-time reconstruction. We present MoViC, a framework that uses live RGB video as a control signal for humanoid robots without wearable tracking devices. The framework combines monocular human motion reconstruction, robot retargeting, and a transformer-based behavior foundation model. The policy receives proprioceptive history, a single explicit next-step…
Ukrainian defense manufacturer Skyfall has developed the “Stargate” carbon-fiber aerial medical evacuation drone to rescue wounded soldiers from frontline “kill zones” inaccessible to medics and ground robots. Capable of flying at 105 km/h with a 150-kilogram payload over a 30-kilometer range, the $50,000 craft uses onboard artificial intelligence to maintain stability during Russian electronic warfare jamming.
As older adults increasingly live alone, emergency support becomes an important function for home companion robots. In Australia, demand for the care and support workforce is projected to nearly double between 2020-21 and 2049-50. Service robots such as robot dogs may support older adults by combining everyday companionship with assistance when human support is not immediately available. We present the design and implementation of a domestic companion-robot system on a…
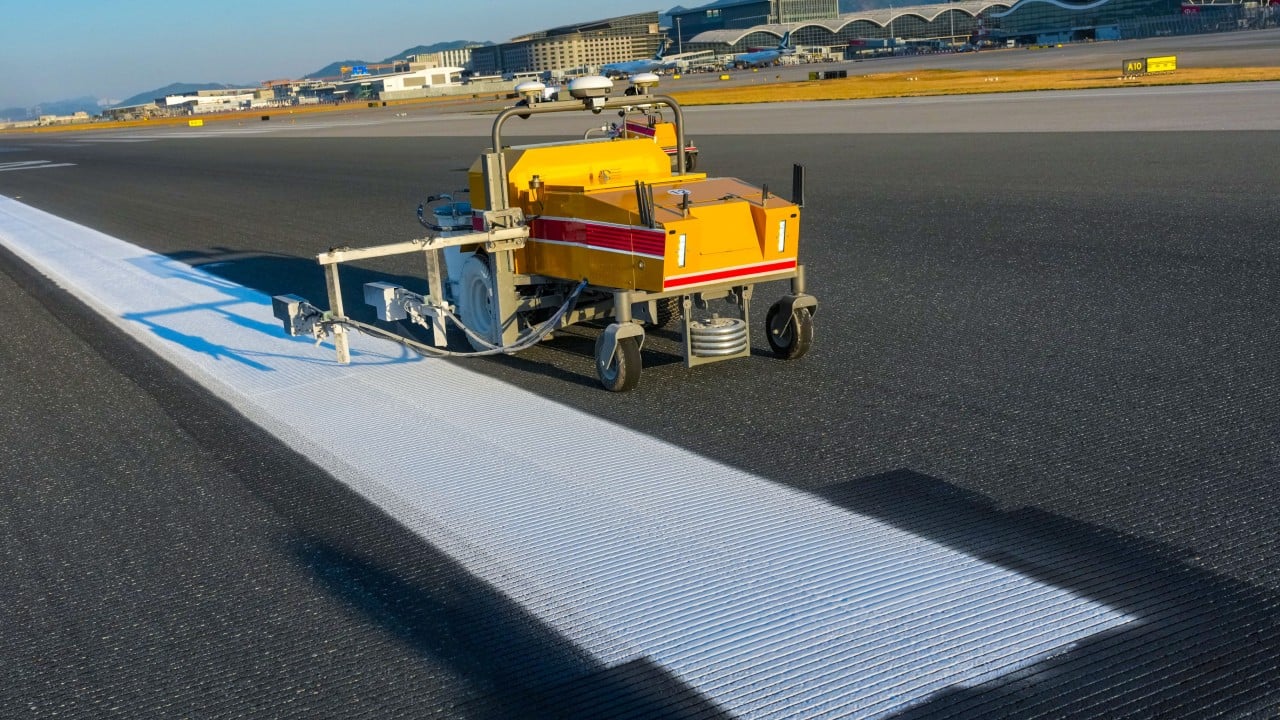
Hong Kong International Airport has become the world’s first to deploy robots to repaint runway markings, cutting the time needed to refresh centre lines by about 67 per cent compared with manual painting, its managing authority has said. According to the Airport Authority, the AI-powered robots, called “Brushman”, also improve painting accuracy and worker safety, reducing the need for physically demanding overnight work and allowing staff to take on supervisory roles…
OpenAI is dissolving its standalone robotics team for the second time, but not because it lacks data. General-purpose models like GPT-6 Astra can apparently control robots directly, making a dedicated unit unnecessary. The researchers are being redistributed across other teams in what the company frames as a way to accelerate its robotics efforts. The article OpenAI reassigns robotics researchers to other teams as general-purpose models might make specialized robotics AI…
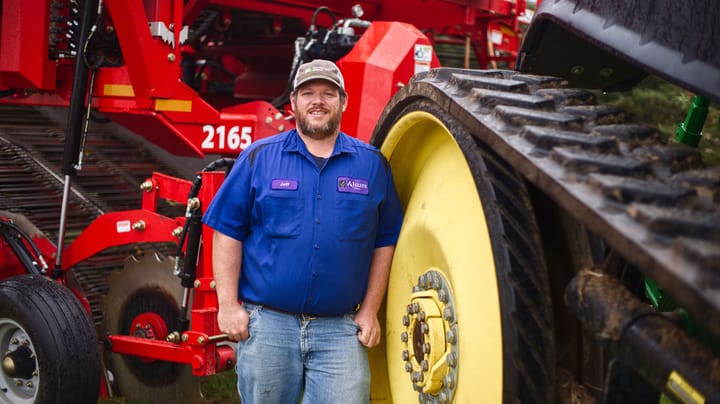
Farmer Iron: From spider robots to drone sprayers, Wisconsin farm showcases the future of agriculture’s workforce.
Lethal autonomous weapons powered by artificial intelligence are set to revolutionise warfare but there is no proper regulatory or legal framework governing the new technology. A conference starting Monday at the United Nations in Geneva will discuss how to establish curbs and prohibitions on such weapons, called killer robots by some. But some analysts doubt the discussions at the Convention on Certain Conventional Weapons (CCW) will keep pace with the fast-changing weapons.
Reinforcement learning (RL) can teach robot teams to navigate shared spaces, but trial and error causes collisions that real robots cannot afford. Control barrier function (CBF) safety filters prevent these collisions by correcting unsafe actions, yet in a team the filter becomes a centralized optimization whose number of constraints grows quadratically with the team size. We propose an approach that builds the filter's safety into the RL policy and examine how such a system…
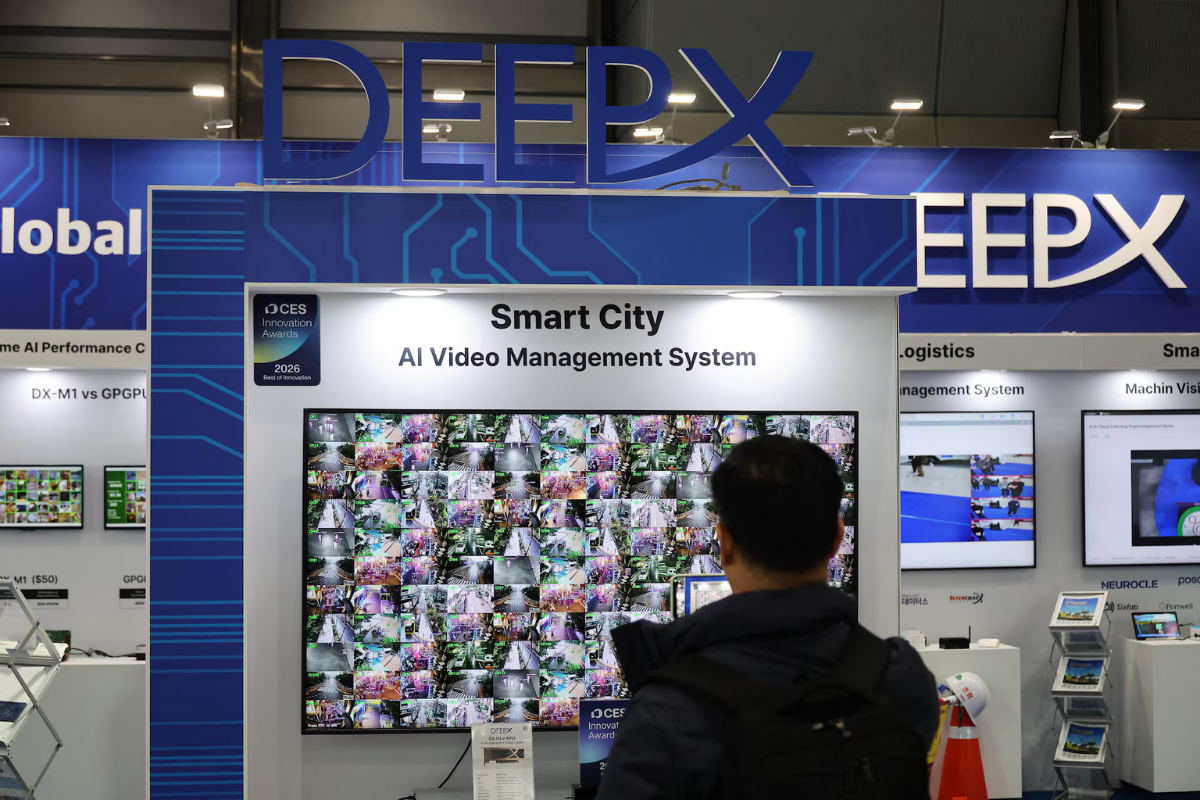
Aimed at robots and AI PCs, the DX-M2 is designed to run generative AI models on about 5 watts.
German defense company ARX Robotics has begun producing and delivering Gereon unmanned ground vehicles equipped with Ukrainian-made Saber combat modules.
Robots in homes, warehouses and farms must pick up objects they have never seen, usually without a 3D model or a category label. A grasping policy that works directly on the point cloud from a depth sensor needs only the geometry the robot observes, so it applies to any new object. Offline grasp generators such as Contact-GraspNet work this way, but they rank grasps by learned plausibility rather than by whether the grasp actually lifts the object. Reinforcement learning…
German defense company ARX Robotics and Ukrainian company Roboneers have delivered the first batch of jointly manufactured Rys Pro unmanned ground vehicles to Ukraine, even before the official establishment of their joint venture, ARX Industries.
Robot-use agents (RUAs) have emerged as a promising approach to general-purpose robot control. However, strong performance has so far been achieved only by frontier proprietary models such as GPT-6 Astra and Claude Fable 5.2, whereas open-weight models remain substantially less capable. We show that an open-weight 27B reasoning model can be trained to use real robots natively through reinforcement learning, entirely in simulation and without demonstrations. Like a…
Accurate friction modeling in continuum robots is essential for precise motion control and path planning. However, current approaches make predictions only for the mechanism's internal friction that is limited by the boundary forces of the Coulomb friction cone, which fail to characterize the static friction and motion hysteresis. In this paper, we propose a novel friction model based on complementarity constraints under the Coulomb friction assumption. This model predicts…
Autonomous robots are widely used for persistent monitoring of spatiotemporal environments, where quantities of interest (QoI) change across space and time and require repeated measurements. In practice, robot motion can be affected by external disturbances that vary across the environment. When such external disturbances are not considered in trajectory optimization, it can lead to inaccurate predictions of robot motion and, consequently, the information acquired about the…
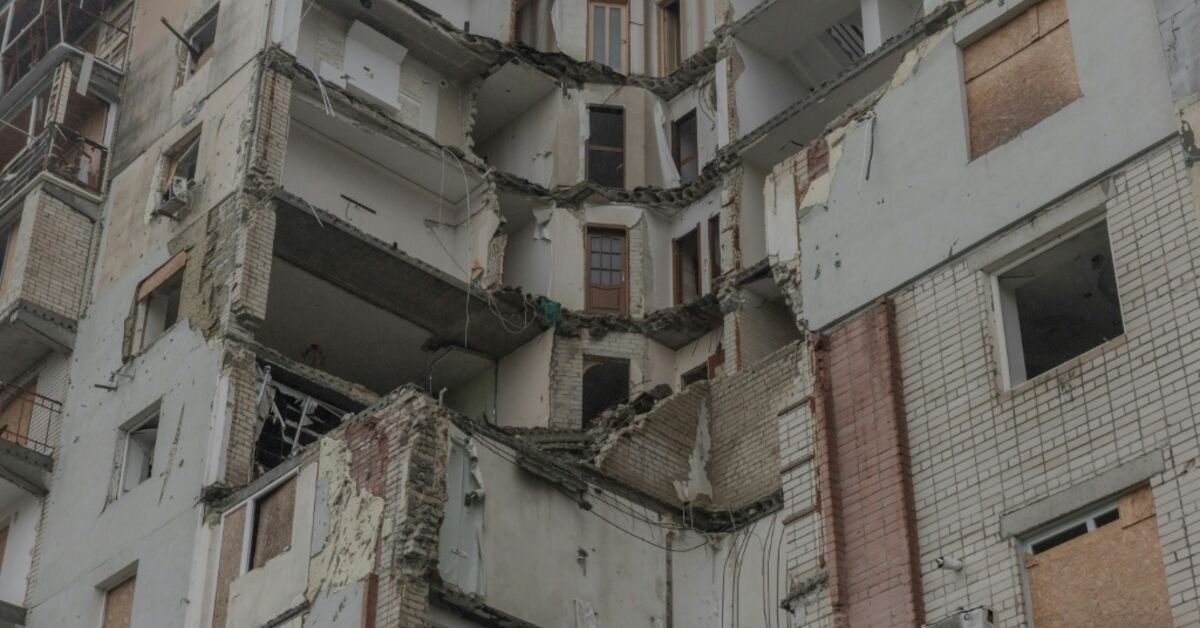
Kyiv's forces are using drones and ground robots to help defend against Russia's army along the about 1,200-km front line snaking down eastern and southeastern Ukraine
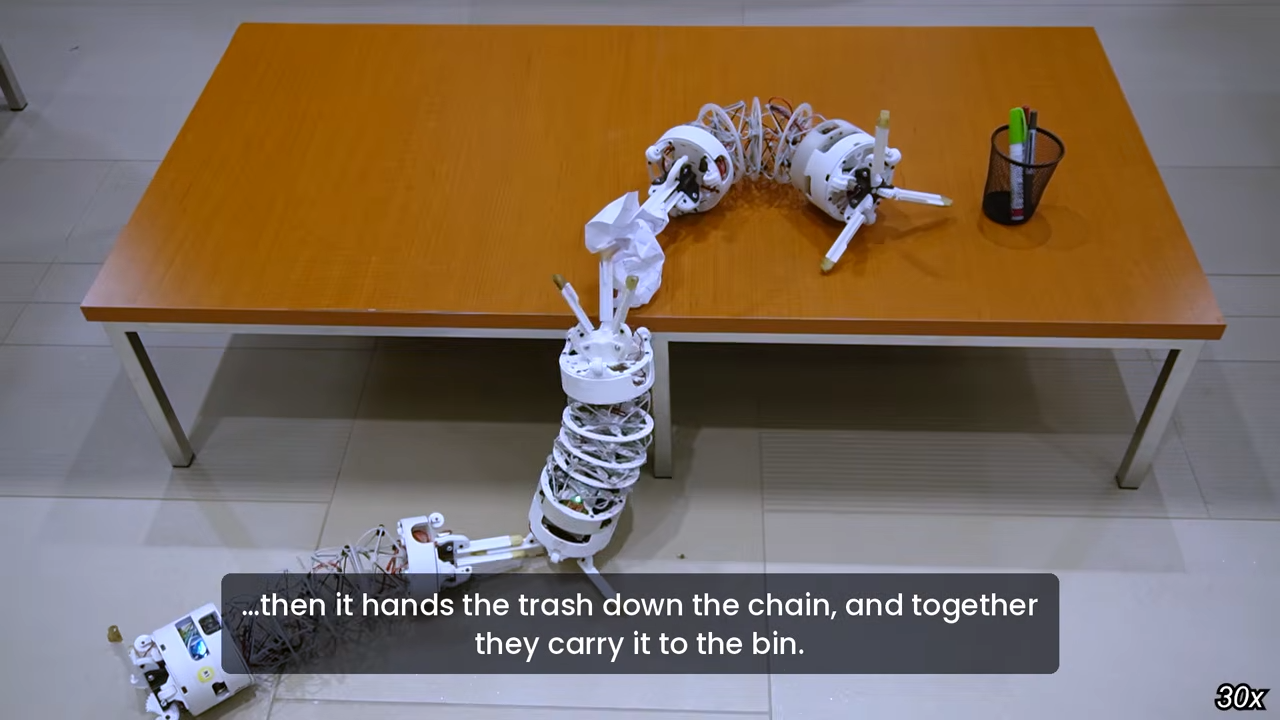
Robots have been a mainstay of our early space exploration efforts. But they normally have wheels. Or in some cases, rotors. While those solutions are great on flat ground, they struggle with jagged boulders or tight crevices. So engineers have been working on alternative robotic form factors, and a recent paper in Nature Machine Intelligence from researchers at Colorado State University’s Adaptive Robotics Lab, describes a unique morphology using a design principle…
Vision-based perceptive locomotion has enabled legged robots to achieve agile and terrain-aware locomotion across complex environments. However, the reliability of such systems heavily depends on visual observations, which are inherently susceptible to occlusion, reflective surfaces, and illumination variations, often resulting in catastrophic locomotion failures under degraded perception conditions. In this paper, we present PROOF (Perceptive Robustness via…
Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments. Daniela Shchegelskaya is an electronics and robotics engineer specialising in autonomous systems, control engineering, and Al-driven robotics for industrial and safety-critical environments. She works on deploying real-world autonomous robots beyond lab conditions, focusing on reliability, connectivity,
Reaching a goal state in a complex environment often requires a robot to overcome challenging terrain and obstacles. Which routes are accessible depends on the robot's physical design, the control policy it uses, and how it modifies its surroundings. We present a kinodynamic rapidly-exploring random tree (RRT) planner that uses physics simulation to exploit skills encoded in the control policy, which allows it to find a path in the scene with respect to the robot's…
El Salvador’s President Nayib Bukele has released a video showing armed robots during an operation against gangs.
Reinforcement learning has enabled robust humanoid locomotion, yet training recipes (rewards, architectures, hyperparameters) remain hard to reuse across robots with different native joint coordinates, since policies output native joint angles while action scales, bounds, gains, and penalties are defined in those robot-specific coordinates. Existing transmission models convert native targets into actuator commands but do not standardize the coordinate interface exposed to…
Service robots in domestic and office environments must identify users to provide personalized services based on their preferences and previous interactions. This is challenging because only a few observations may be available for learning, while observation conditions change owing to appearance, environmental noise, and utterance content. To address this challenge, this study proposes a multimodal person concept model that learns person concepts from a small number of…
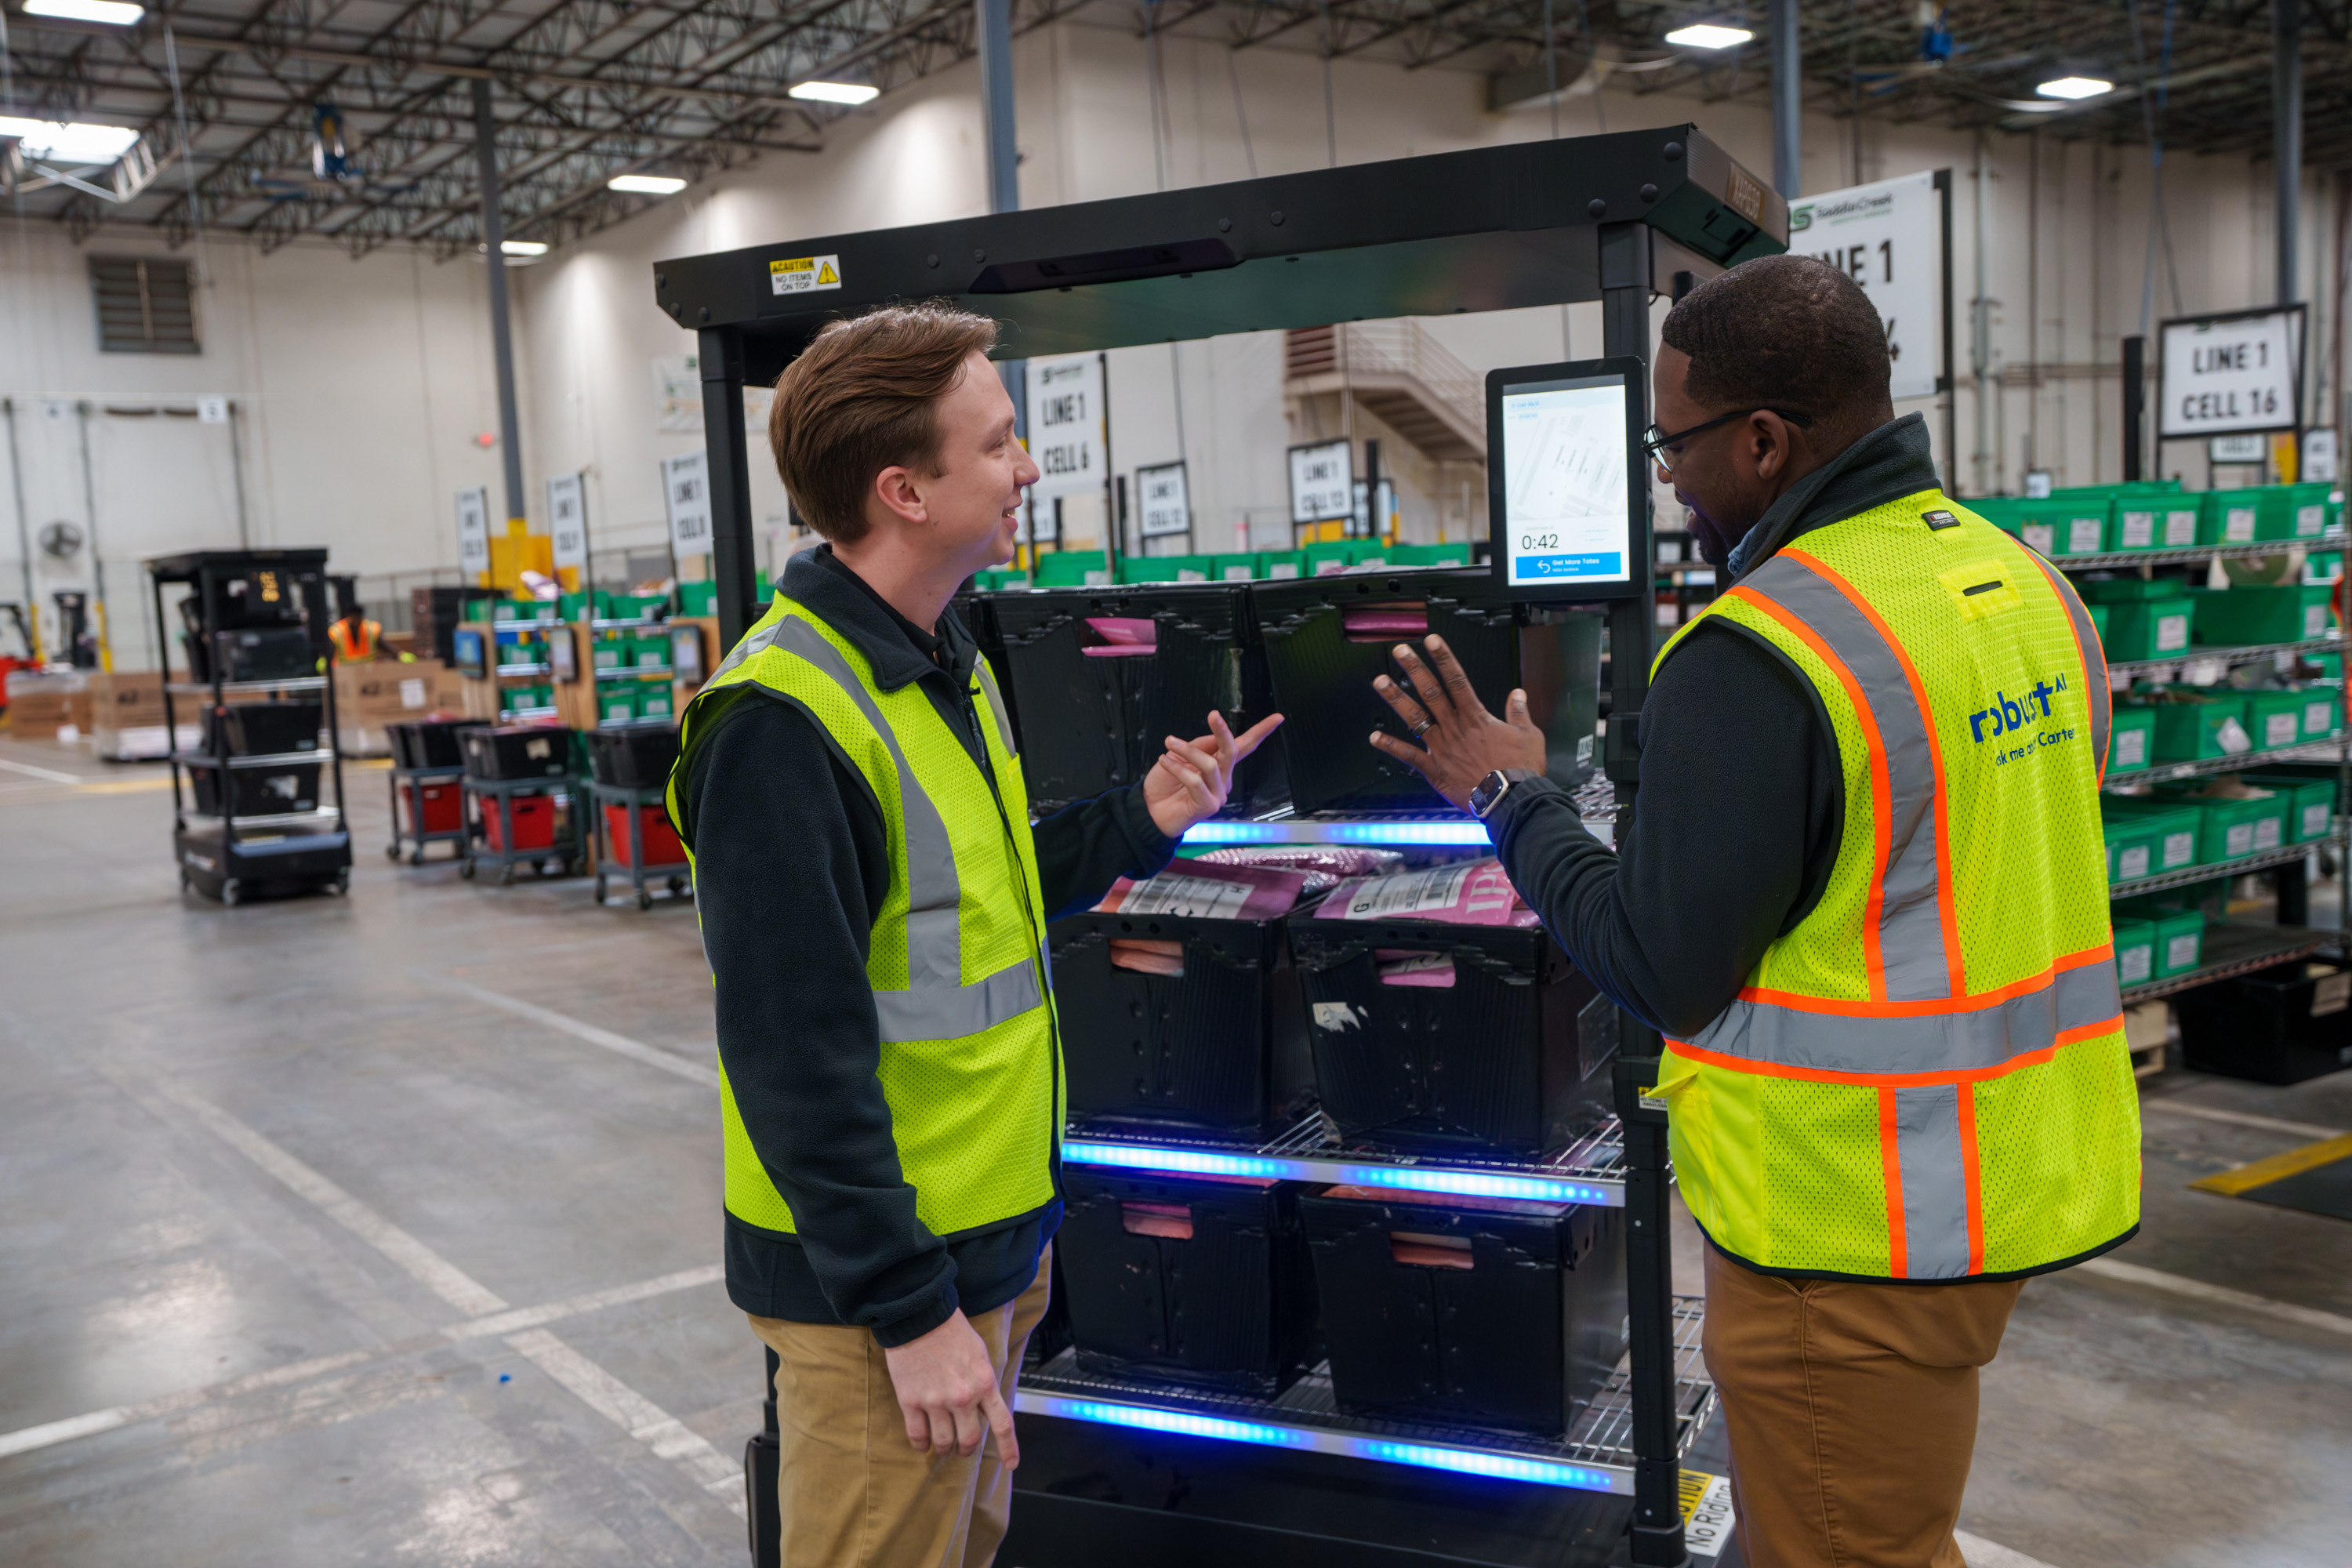
Founded by Anthony Jules ’92, SM ’92 and Professor Emeritus Rodney Brooks, Robust AI’s robots are designed to collaborate with humans in factories and warehouses.
Long-horizon navigation from indoors to outdoors remains an open problem for humanoid robots: one instruction covers rooms, doors and roads, and the camera moves with the gait. Worken, AGIBOT's measure of productive robot work, depends on robots that reach their workplaces autonomously. We present X-Nav, to our knowledge the first system to take a bipedal humanoid through a language-instructed long-horizon mission from indoors to outdoors. X-Nav covers a pipeline from data…
Robots with weak motors must ride their natural dynamics rather than fight them. We swing up a direct-drive planar two-link robot, whose motors deliver only about 6\,\% of its shoulder gravity torque, along its nonlinear normal modes, two-dimensional invariant manifolds consisting of periodic orbits. On a non-strict mode, injecting energy necessarily moves the state off the manifold, so pumping and stabilization compete for the same bounded torque. We split the input torque…
For robots to assist, serve, and collaborate with humans, they must not only interpret human requests conveyed through language and multimodal intentional cues, but also execute long-horizon tasks that interleave navigation and manipulation. In this paper, we introduce HEIR, a resource for studying how to Harness Egocentric Intent for Human-Robot Interaction. HEIR pairs human speech, measured gaze, and egocentric video with robot observations and teleoperated…
Multi-robot systems face the challenge of efficiently allocating teams of heterogeneous robots to tasks. The task allocation problem is complicated by collaborative interactions between robots where teams of robots develop emergent capabilities that enable them to complete tasks that would be inefficient or impossible for individual robots. To address these challenges, we present an iterative clustering algorithm for collaborative task allocation in heterogeneous multi-robot…