Results for “Robots”

Tech.eu Tamara Djurickovic Startups

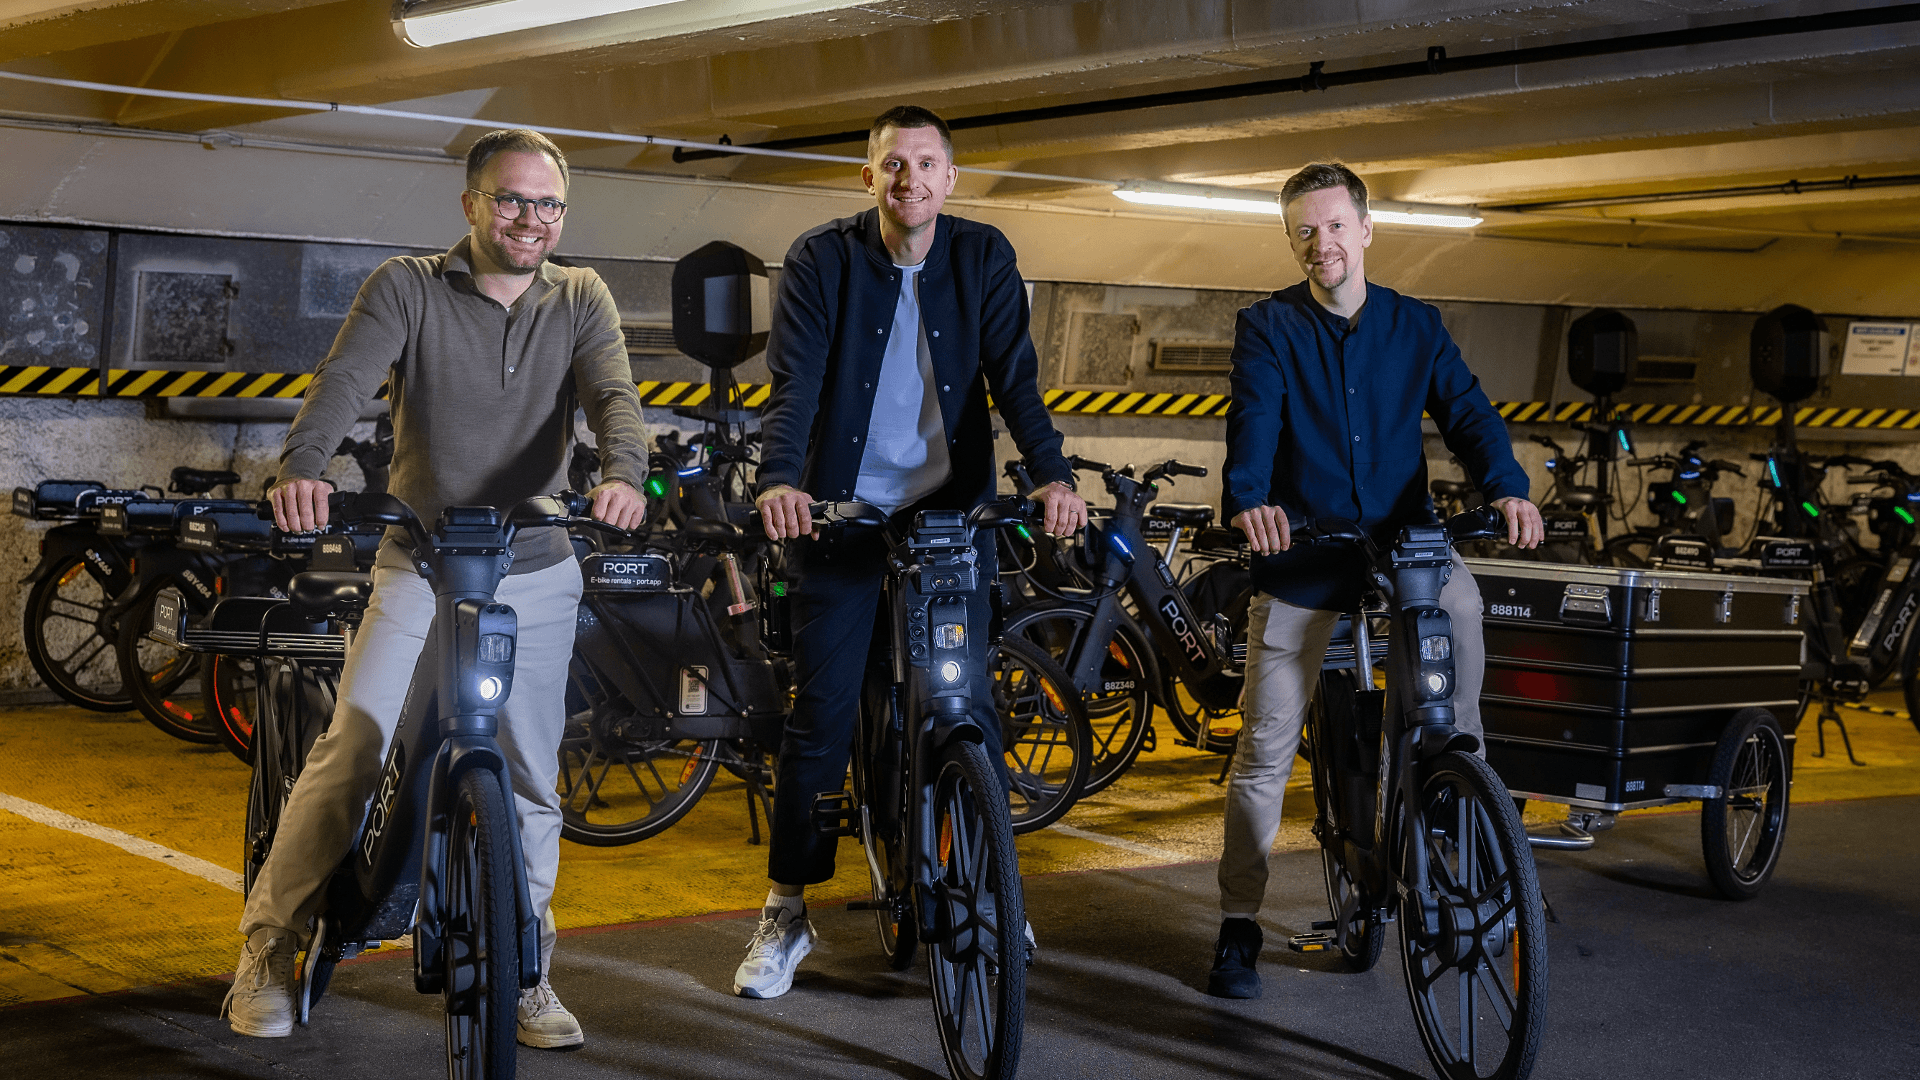
PORT raises €14.5M to take urban logistics from e-bikes to autonomous robots

Urban logistics company PORT has raised €14.5 million in afunding round led by the European Bank for Reconstruction and Development(EBRD) and Balnord, with participation from existing and new investor...
Read at Tech.eu

Tech in Asia Minh Le Startups

Ant Group’s Robbyant open-sources tactile AI model

The model helps robots process touch signals from different sensor types through a shared representation.

Read at Tech in Asia

Sixth Tone Wu Huiyuan

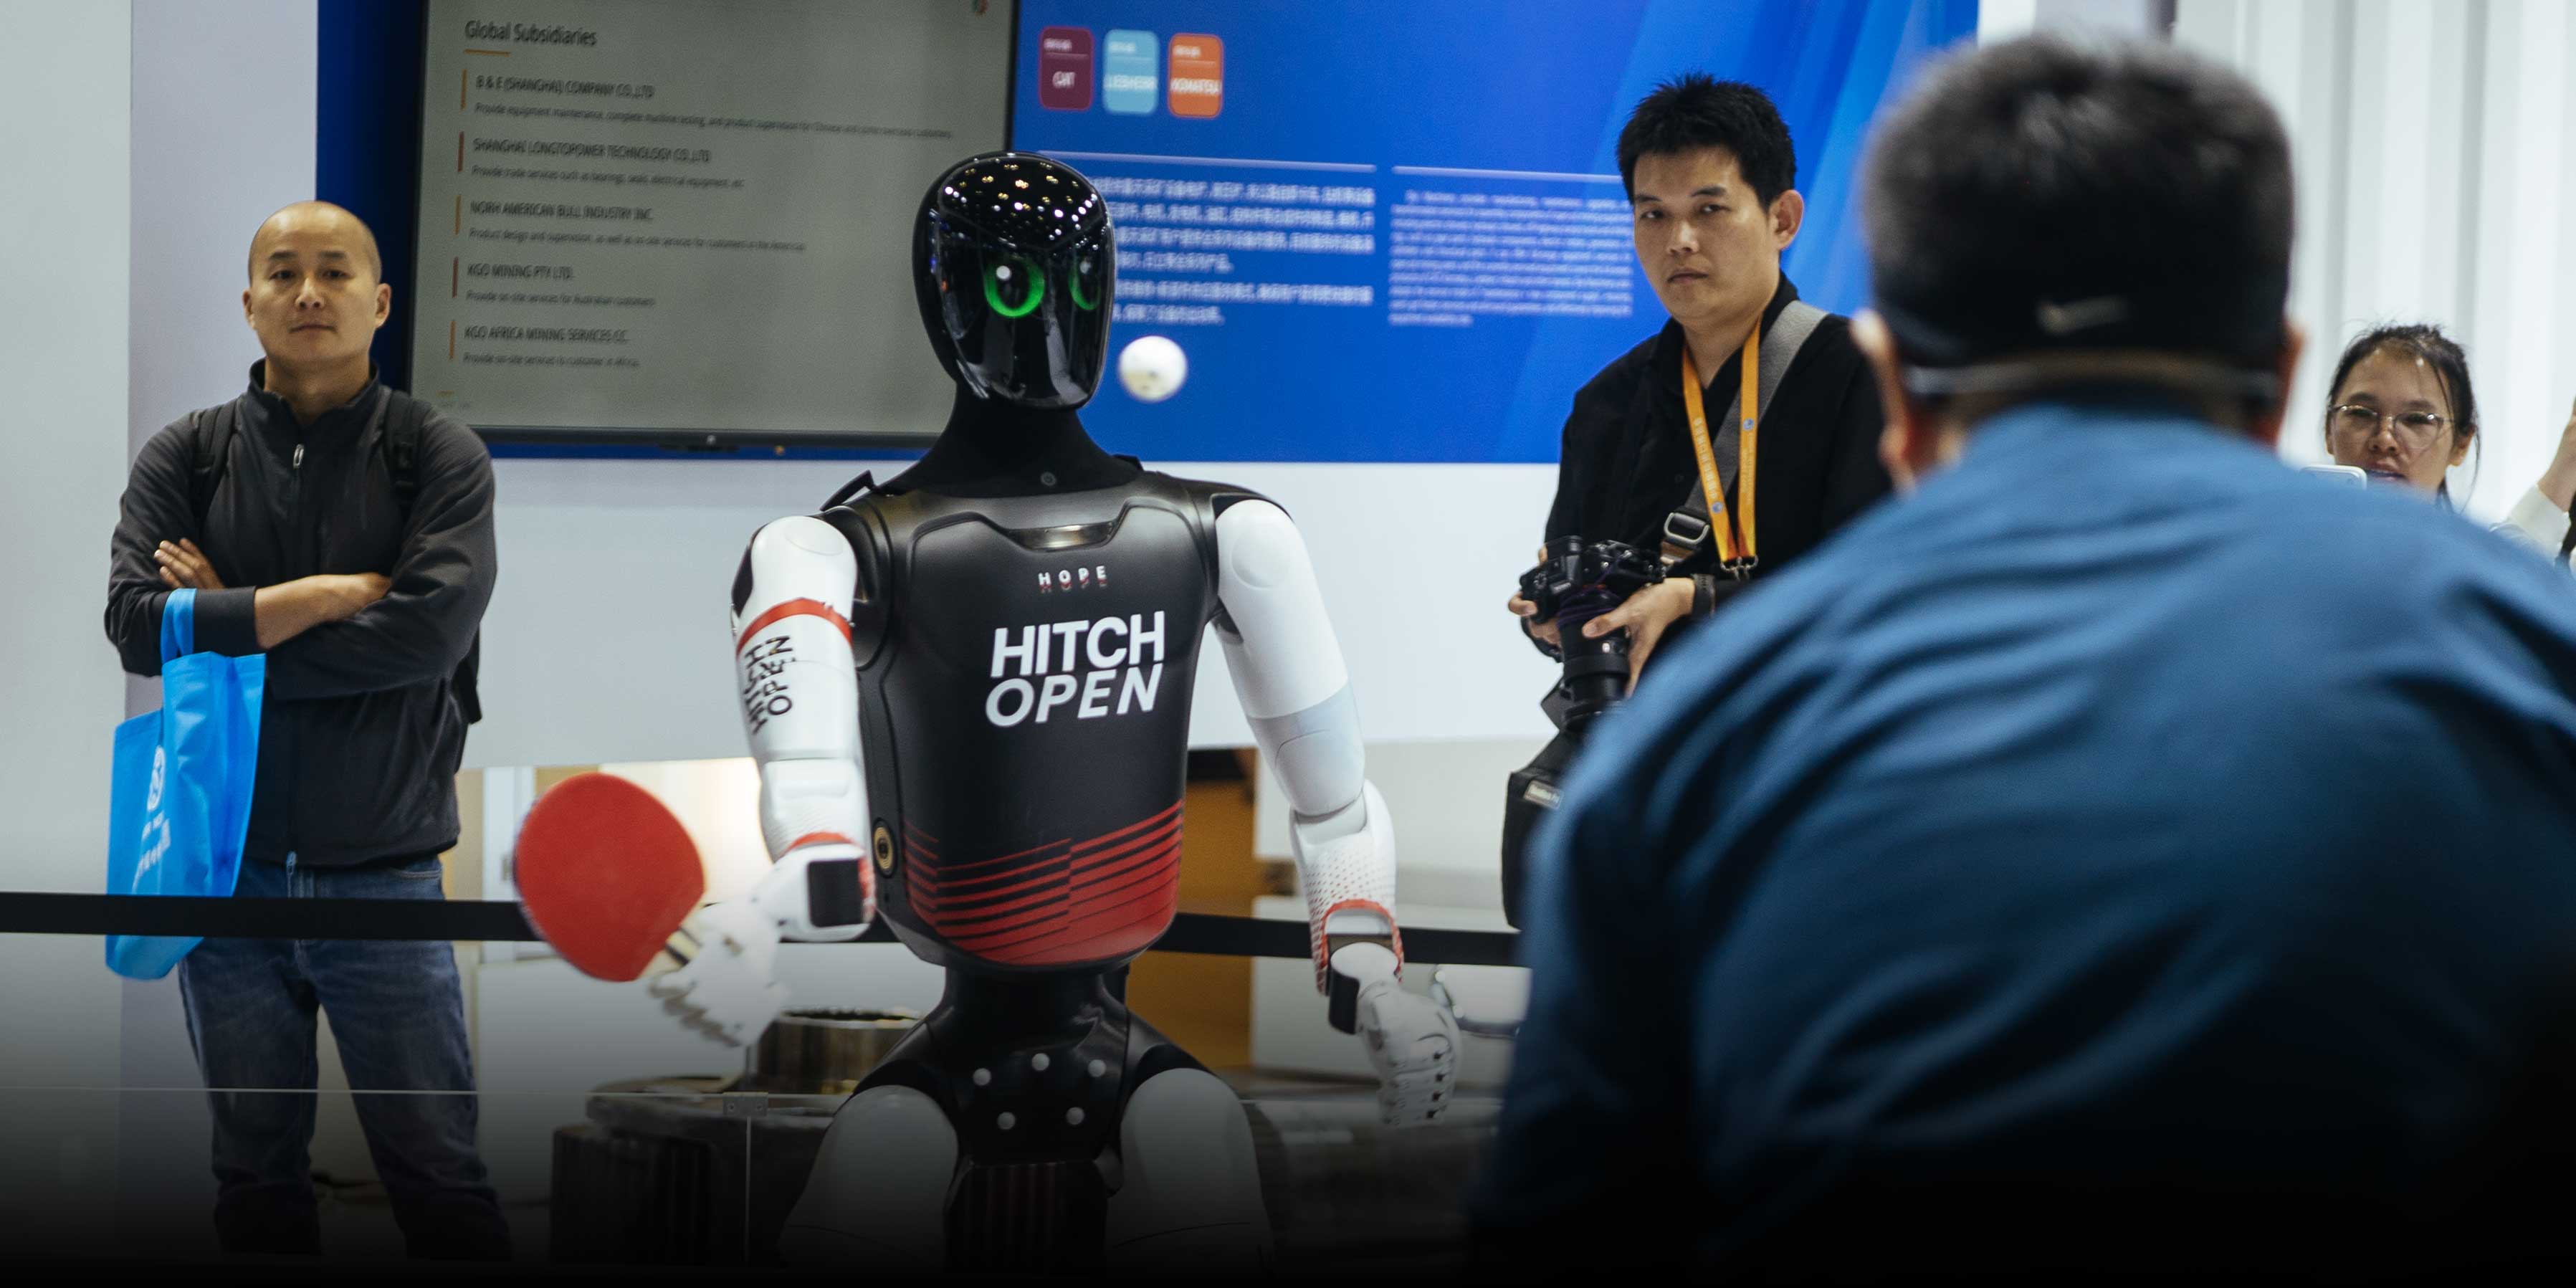
Collage: Robots, Health and New Tech at China Expo

From humanoid robots taking on human tasks to advances in medical technology, snapshots of the products, innovations, and experiences on display at the ninth China International Import Expo.

Read at Sixth Tone

Universe Today Matthew Williams Space

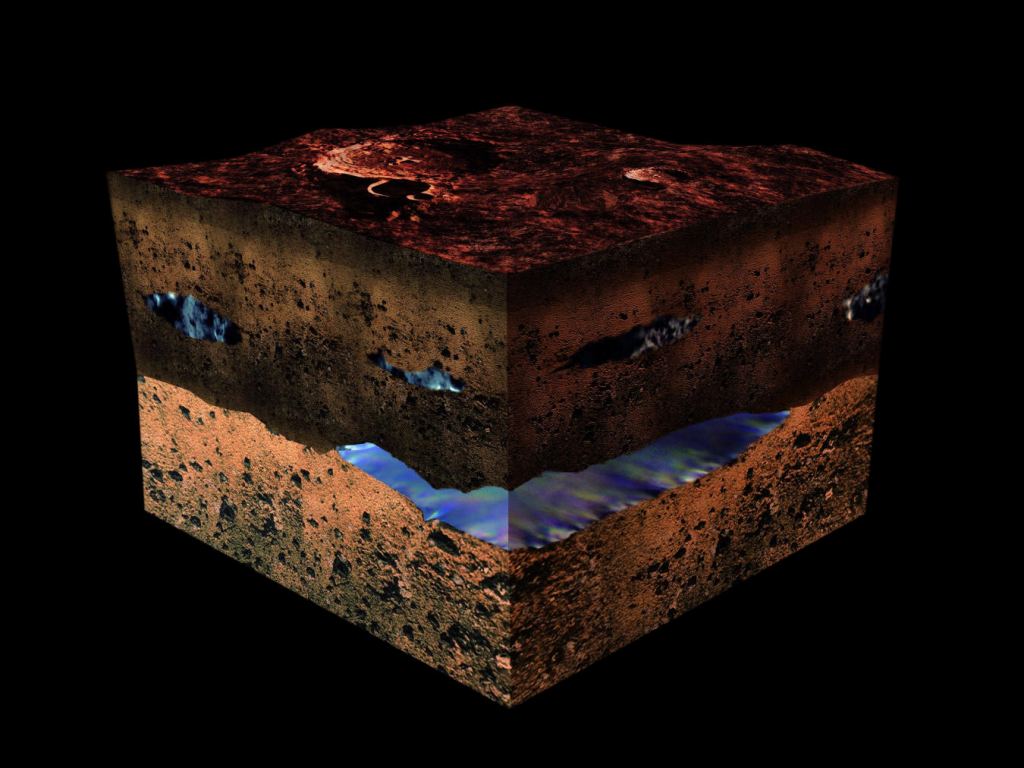
Using Vibrations and AI, Future Robotic Missions Could Handle Buried Rocks Autonomously

Mechanical engineering assistant professor Erik Komendera developed a method that combines vibrations and AI to determine how deeply a rock is buried, helping robots clear terrain more efficiently.

Read at Universe Today

Dark Reading Kristina Beek Security

PwC's CISO on AI, Robots & What's Next for Security

As AI accelerates change across the enterprise, PwC's James Shira explains why security teams must rethink their approach to risk and adapt their strategies.

Read at Dark Reading

IEEE Spectrum Robotics Evan Ackerman

Can Agentic Robotics Solve Robotics’ Data-Scaling Problem?

Robotics companies are investing heavily in the belief that data will solve the most difficult problems in robotics. Once AI systems have ingested enough data from human demonstrations, the thinking goes, robots will be able to perform the vast majority of the manual tasks that humans now do. There are even robotics companies that exist solely to collect training data and sell it to other robotics companies in pursuit of this goal. But whether data will finally bring us…

Read at IEEE Spectrum Robotics

NVIDIA Blog Sasa Docca SI

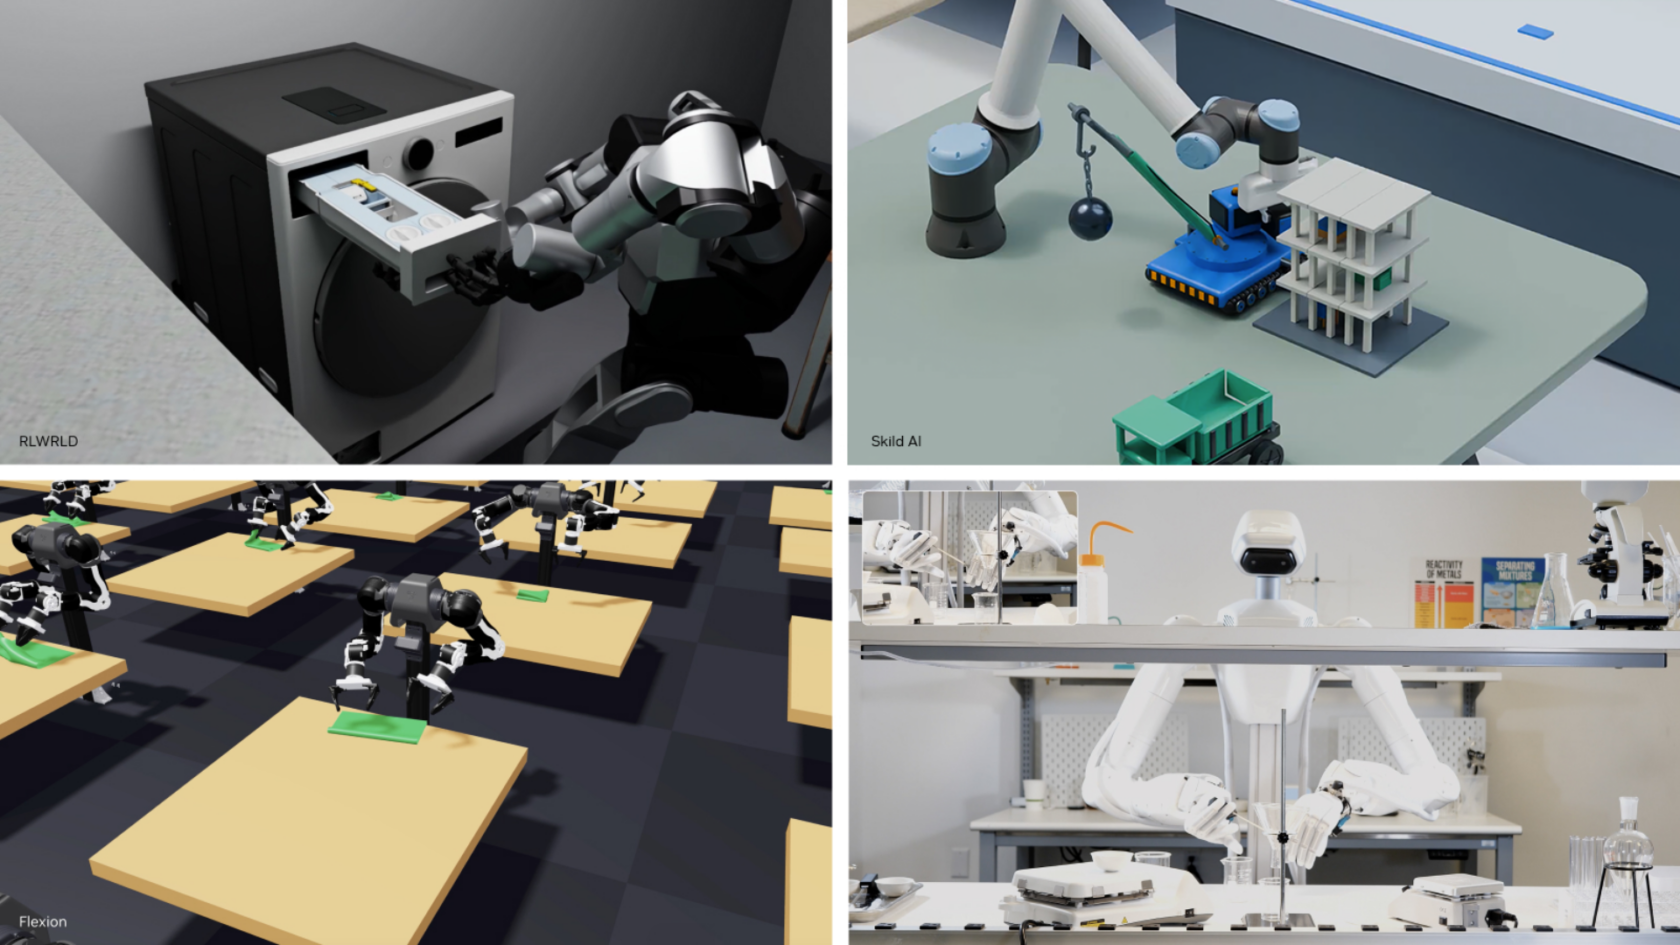
Practice Makes Precise: At CoRL, NVIDIA and Partners Reveal How Robots Rehearse Delicate Work in Simulation

Simulation, which has long been the proving ground for robots learning to walk, roll and hop, is now helping researchers teach robots tasks that require a finer touch: aligning gears, connecting cables and assembling small components. The shift from locomotion to manipulation is taking center stage at this week’s Conference on Robot Learning (CoRL) in

Read at NVIDIA Blog

Hackster.io Gareth Halfacree https://www.hackster.io/ghalfacree

NXP Unveils Its Unified Robotics Platform, Complete with Ready-in-30-Minutes Drone Reference Design

New platform will cover everything from drones to, in a future release, autonomous mobile and humanoid robots, NXP says.

Read at Hackster.io

WIRED Ritsuko Kawai

These Robotic Arms Are Powered by Algae. Watch How They Move

The key to the movement of these flexible robots is the algae’s photosynthetic capabilities.

Read at WIRED

Axios Zachary Basu Geopolitics

Elon Musk's empire braces for Democratic crackdown

Elon Musk's sprawling empire — from rockets to robots, electric cars to AI — is facing a political onslaught with few parallels in modern corporate history. Why it matters: The world's richest man confronts a constellation of risks spanning the halls of Congress, his Texas industrial empire, Wall Street and his vision for AI supremacy. 💰 Political: To Democrats, Musk embodies corrosive forces of the MAGA era — extreme wealth, billionaire influence over government, the…

Read at Axios

Tech in Asia Diya Lal Startups

China’s UBTech, Tianyi team up to scale humanoid robot market

The firms also aim to help biomimetic and wheeled humanoid robots surpass 100,000 units.

Read at Tech in Asia

Future Farming Geert Hekkert

Who is to blame if an agricultural robot kills someone?

Autonomous tractors and robots are gradually making their way onto farms. There are several reasons why we are unlikely to see a massive wave of adoption just yet. One is the uncertainty surrounding legislation and liability. After all, what happens if a driverless tractor causes a fatal accident? Who is responsible? The farmer, the manufacturer or the software developer? This is a question the agricultural industry will be grappling with for years to come.

Read at Future Farming

MIT News AI Jennifer Chu | MIT News SI

AI-assisted learning platform helps robots reason beyond literal commands

The new approach, known as FLEX, could lead to more intuitive, interactive household and assistive robots.

Read at MIT News AI

MIT News AI Adam Zewe | MIT News SI

A single AI model simulates the behavior of many substances, from sliding sand to folding proteins

By learning how matter moves, the WorldParticle system could assist with developing soft robots, medicines, and more.

Read at MIT News AI

Journal articles (OpenAlex) Changjian Wang, Zhang Tianyou · Frontiers in Psychology

Empirical study on how lower limb exoskeleton robots improve older adults’ physical performance through psychological mechanisms

Objective This study aims to explore how lower limb exoskeleton robots enhance physical performance in older adults and clarify the mediating role of psychological factors during human-robot interaction exercises. Methods The study focused on healthy older adults in the community and used a randomized controlled trial design along with qualitative research methods. A total of 60 participants aged 60–75 were selected and divided into an lower limb exoskeleton robots…

Read at Journal articles (OpenAlex)

WIRED Reece Rogers SI

World Models Will Soon Be Inescapable. Here’s What You Need to Know

Moving AI from text to 3D space, world models simulate real-world physics to teach robots and autonomous cars how to navigate reality.

Read at WIRED

arXiv (research papers) Zhengyang Cheng

Efficient VLA Inference via Retrieval-Based Speculation and Hardware Acceleration

Vision-language-action (VLA) models enable robots to understand and execute complex instructions, but their autoregressive (AR) action generation introduces significant latency on resource-constrained robotic platforms. Speculative decoding can accelerate AR-based inference by parallelizing action generation and verification; however, existing approaches rely on costly draft models, which are inefficient on edge platforms. In this paper, we propose Zora, a hardware-software…

Read at arXiv (research papers)

Journal articles (OpenAlex) Minyang Wang, Bangcheng Zhang, Zhi Wei Gao · Mathematics

An Uncertainty-Adaptive Robust Graph-Based Belief Rule Base for Interpretable Four-State Fault Diagnosis of Industrial Robots

Industrial robot severity diagnosis must combine evidence from coupled subsystems while remaining stable under fluctuating measurements. We develop an uncertainty-adaptive robust graph-based belief rule base (RG-BRB) that maps monitored attributes to transmission, servo-control, and motion-execution nodes. A row-stochastic graph propagates node evidence, while local fluctuation adjusts antecedent widths and attribute reliability before rule activation. Normalized evidential…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Shih‐Hao Chang, Minyechil Alehegn Tefera, Jun-Ming Cheng et al. · Sensors

Vision-Guided Robotic Arm with Deep Learning and Secure Digital Twin for Pre-Deployment Quadruped Robot Operation

In this article, we propose a vision-guided robotic arm system that integrates deep learning, digital twin, and cybersecurity to enhance the maintenance of quadruped robots. The proposed system comprises two core components. (1) A YOLOv11-based object detection system with depth cameras identifies maintenance targets and extracts 3D coordinates for autonomous robotic arm localization and manipulation. (2) A digital twin environment is used to simulate and validate path…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Hao Yun-gang, Qi-Xin Zhu, Peng Chen et al. · Actuators

Rigid–Flexible Coupling Design and Variable Stiffness Control of Drive Mechanism Components for Ostrich-Inspired Robots

Ostriches are the fastest bipedal terrestrial animals. Their hip, knee, and ankle joints possess inherent shock-absorbing capabilities, endowing their legs with excellent compliance. This biomechanical feature ensures both stability and high energy efficiency during high-speed locomotion. For ostrich-inspired robots, designing the leg drive mechanism and implementing compliance control are crucial for achieving biomimetic locomotion. Therefore, this study focuses on the knee…

Read at Journal articles (OpenAlex)

Space.com Space.com Staff Space

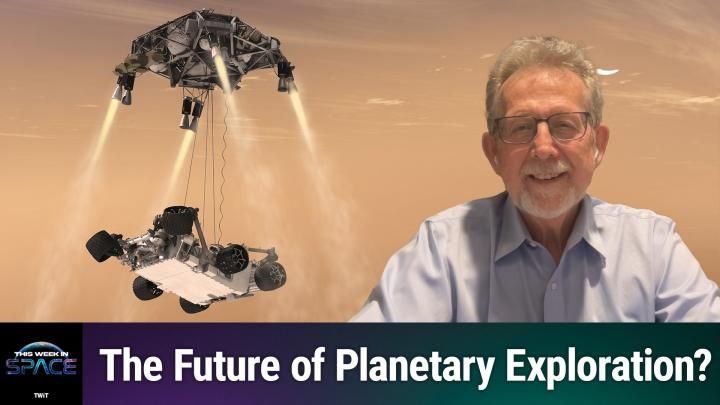
This Week In Space podcast: Episode 235 — Robots in Dark and Scary Places

On Episode 235 of This Week In Space, Tariq Malik and Rod Pyle are joined by Dr. Jim Green to talk about the past, present, and future of planetary exploration.

Read at Space.com

Journal articles (OpenAlex) Xiaohan Ji, Yiming Guo, Haichao Zhang et al. · Applied Sciences

Adaptive Predefined-Time Servo Tracking Control for Logistics Wheeled Mobile Robots in Warehouse Handling

Warehouse logistics systems increasingly require rapid and efficient material transfer. Wheeled mobile robots (WMRs), as flexible automated handling equipment, are being widely adopted for warehouse transport. This paper addresses the trajectory-tracking problem of a WMR subject to external disturbances in warehouse handling scenarios and proposes an adaptive trajectory tracking control method with a convergence time that can be specified in advance. A Lyapunov-based…

Read at Journal articles (OpenAlex)

arXiv (research papers) Prerana Ramkumar

The World Model Planning Accelerator (WMPA): Hardware-Algorithm Co-Design for Embedded AI in Robotics

Embedded AI is moving from perception to prediction. Robots now use world models$\unicode{x2014}$learned simulators that predict the outcome of candidate actions in a compressed latent space before any is executed. Every predicted step must be computed on board within a tight power and thermal budget, yet the energy these steps fundamentally require, and how far real hardware sits from it, have not been characterized. We derive lower bounds on the arithmetic operations and…

Read at arXiv (research papers)

Robohub Robot Talk

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment. Dexter Shepherd is a Postdoctoral Researcher at the University of Sussex, exploring machine learning for bio-inspired tactile sensing and robotic locomotion. His work combines embedded AI systems, spatial-temporal models, and reinforcement learning

Read at Robohub

TechCrunch Tim Fernholz Startups

Physicl raises $10M to make the digital world real enough for robots

Physicl is trying to solve the sim-to-real gap with a pipeline originally built to market goods online.

Read at TechCrunch

Journal articles (OpenAlex) Bożena Gajdzik, Radosław Wolniak · Robotics

Humanoid Robots: Applications, Commercial Readiness, and Challenges

Humanoid robots are moving from laboratory prototypes toward practical deployment in industrial and service environments. This study examines their current applications and assesses commercial readiness through a structured synthesis of the scientific literature, institutional and market reports, manufacturers’ materials, and documented pilot and deployment projects. The findings show that automotive manufacturing, warehousing, and logistics currently provide the strongest…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Yanchen Ye, Can Xu, Sen Wang et al. · Science Advances

Adaptive dual-programming magnetic soft robot with lifelike behavior

Magnetic soft robots with embodied intelligence of multimodal motions, environmental perception, and functional decoupling depend on ingenious material arrangement and programmable morphing information introduction. While some efforts have been made, achieving lifelike behaviors for soft robots in system-level strategy remains a notable challenge. Here, we present dual-programming hydrogel-based soft robots (DHSRs) that couple magnetic and anisotropic programming through the…

Read at Journal articles (OpenAlex)

Journal articles (OpenAlex) Chuang Zhi Wu, Chongjing Cao · Actuators

Constraint Mechanism Design for Fast Dielectric Elastomer Actuator-Driven Capsule Robots

Dielectric elastomer actuator (DEA)-driven capsule robots convert periodic excitations into net translation through passive constraints, yet a systematic study on optimal constraint design remains largely unexplored. To address this gap, we present a comparative numerical study of six passive constraint families that range from linear and bistable springs to limit stops and polynomial shapes and encompass 2447 configurations under a reference condition. The best…

Read at Journal articles (OpenAlex)

Older stories